

Paper Menu >>
Journal Menu >>
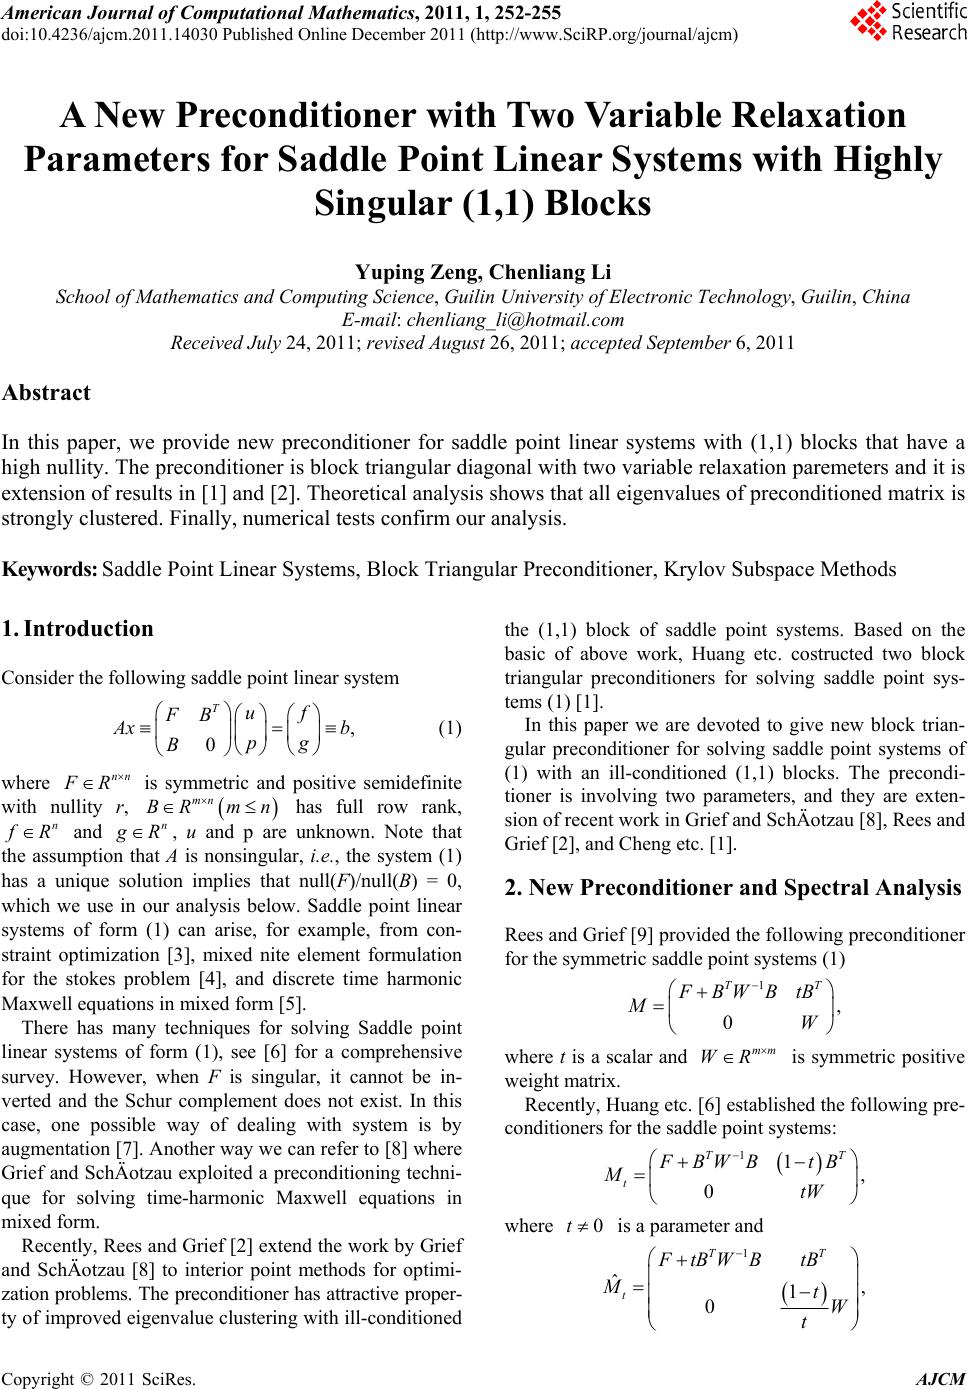 American Journal of Computational Mathematics, 2011, 1, 252-255 doi:10.4236/ajcm.2011.14030 Published Online December 2011 (http://www.SciRP.org/journal/ajcm) Copyright © 2011 SciRes. AJCM A New Preconditioner with Two Variable Relaxation Parameters for Saddle Point Linear Systems with Highly Singular (1,1) Blocks Yuping Zeng, Chenliang Li School of Mathematics and Computing Science, Guilin University of Electronic Technology, Guilin, China E-mail: [email protected] Received July 24, 2011; revised August 26, 2011; accepted September 6, 2011 Abstract In this paper, we provide new preconditioner for saddle point linear systems with (1,1) blocks that have a high nullity. The preconditioner is block triangular diagonal with two variable relaxation paremeters and it is extension of results in [1] and [2]. Theoretical analysis shows that all eigenvalues of preconditioned matrix is strongly clustered. Finally, numerical tests confirm our analysis. Keywords: Saddle Point Linear Systems, Block Triangular Preconditioner, Krylov Subspace Methods 1. Introduction Consider the following saddle point linear system , 0 Tuf FB A x pg B b (1) where nn F R n is symmetric and positive semidefinite with nullity r, has full row rank, mn BR mn f R and n g R, u and p are unknown. Note that the assumption that A is nonsingular, i.e., the system (1) has a unique solution implies that null(F)/null(B) = 0, which we use in our analysis below. Saddle point linear systems of form (1) can arise, for example, from con- straint optimization [3], mixed nite element formulation for the stokes problem [4], and discrete time harmonic Maxwell equations in mixed form [5]. There has many techniques for solving Saddle point linear systems of form (1), see [6] for a comprehensive survey. However, when F is singular, it cannot be in- verted and the Schur complement does not exist. In this case, one possible way of dealing with system is by augmentation [7]. Another way we can refer to [8] where Grief and SchÄotzau exploited a preconditioning techni- que for solving time-harmonic Maxwell equations in mixed form. Recently, Rees and Grief [2] extend the work by Grief and SchÄotzau [8] to interior point methods for optimi- zation problems. The preconditioner has attractive proper- ty of improved eigenvalue clustering with ill-conditioned the (1,1) block of saddle point systems. Based on the basic of above work, Huang etc. costructed two block triangular preconditioners for solving saddle point sys- tems (1) [1]. In this paper we are devoted to give new block trian- gular preconditioner for solving saddle point systems of (1) with an ill-conditioned (1,1) blocks. The precondi- tioner is involving two parameters, and they are exten- sion of recent work in Grief and SchÄotzau [8], Rees and Grief [2], and Cheng etc. [1]. 2. New Preconditioner and Spectral Analysis Rees and Grief [9] provided the following preconditioner for the symmetric saddle point systems (1) 1 , 0 TT FBWBtB MW where t is a scalar and is symmetric positive weight matrix. mm WR Recently, Huang etc. [6] established the following pre- conditioners for the saddle point systems: 11, 0 TT t FBWBtB MtW where 0t is a parameter and 1 ˆ, 1 0 TT t FtBWB tB MtW t 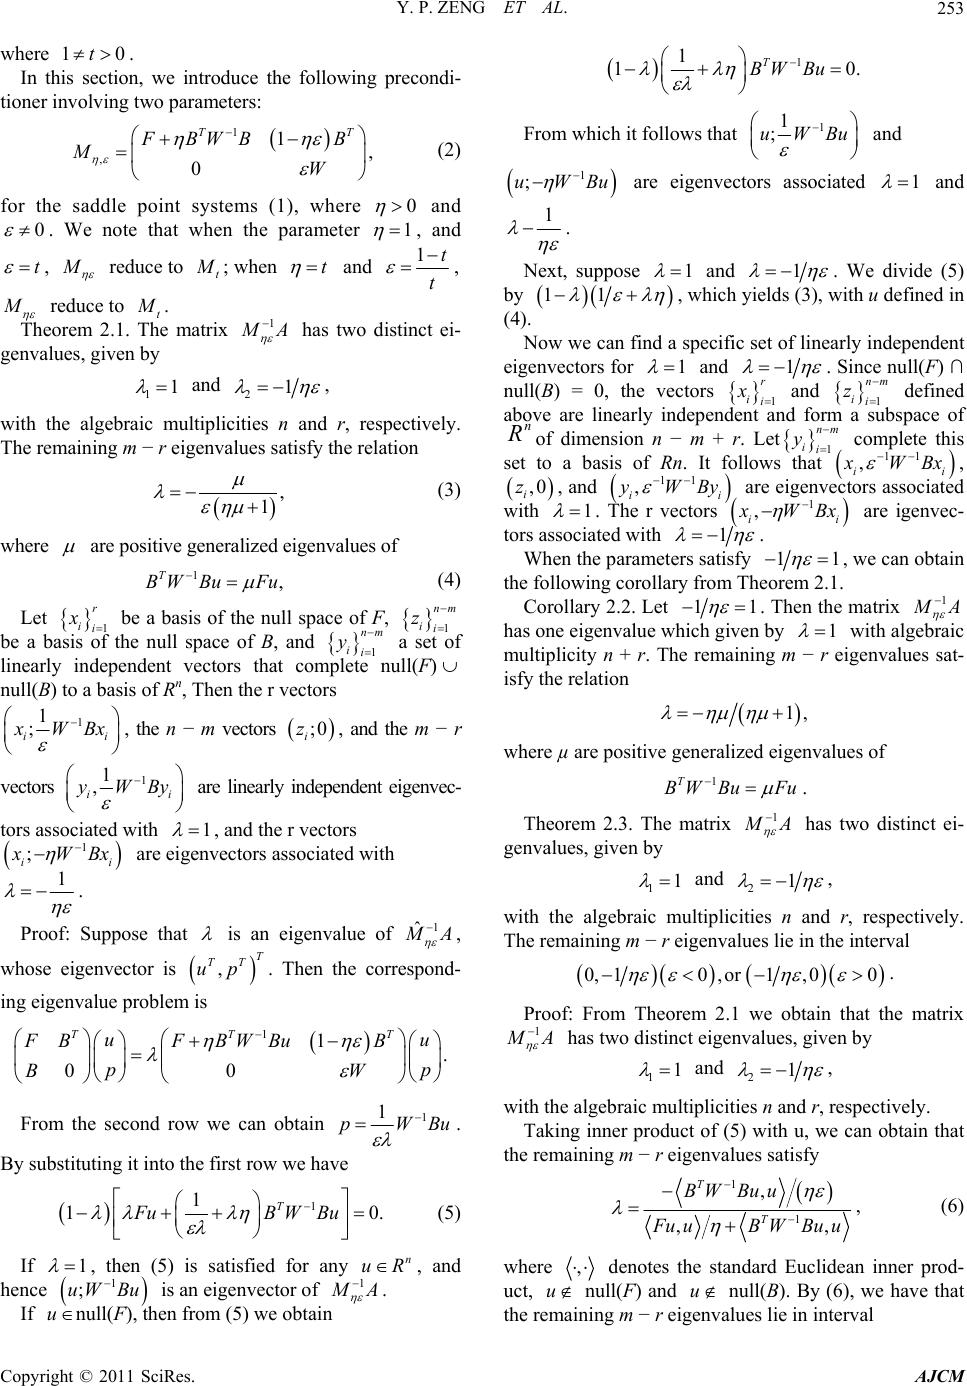 Y. P. ZENG ET AL.253 where . 10t In this section, we introduce the following precondi- tioner involving two parameters: 1 , 1, 0 TT FBWB B MW (2) for the saddle point systems (1), where 0 and 0 . We note that when the parameter 1 , and t , M reduce to t M ; when t and 1t t , M reduce to t M . Theorem 2.1. The matrix 1 M A has two distinct ei- genvalues, given by 11 and 21 , with the algebraic multiplicities n and r, respectively. The remaining m − r eigenvalues satisfy the relation , 1 (3) where are positive generalized eigenvalues of 1, T B WBuFu (4) Let 1i be a basis of the null space of F, 1i r i x nm i z be a basis of the null space of B, and 1i a set of linearly independent vectors that complete null(F) null(B) to a basis of Rn, Then the r vectors nm i y 1 1 ; ii x WBx , the n − m vectors , and the m − r vectors ;0 i z 1 1 , i yWBy i are linearly independent eigenvec- tors associated with 1 , and the r vectors 1 ; i i x WBx are eigenvectors associated with 1 . Proof: Suppose that is an eigenvalue of 1 ˆ M A , whose eigenvector is . Then the correspond- T u p ,T TT up ing eigenvalue problem is 11. 00 TT u FBF BWBuB p BW From the second row we can obtain 1 1 pWB u . By substituting it into the first row we have 1 1 10 T FuB WBu . (5) If 1 ;uW , then (5) is satisfied for any , and hence is an eigenvector of n uR 1 1Bu M A . If null(F), then from (5) we obtain u 1 1 10 T BW Bu . From which it follows that 1 1 ;uWBu and 1 ;uWBu are eigenvectors associated 1 and 1 . Next, suppose 1 and 1 . We divide (5) by 11 , which yields (3), with u defined in (4). Now we can find a specific set of linearly independent eigenvectors for 1 and 1 . Since null(F) ∩ null(B) = 0, the vectors 1i and 1i r i x nm i z defined above are linearly independent and form a subspace of n R of dimension n − m + r. Let 1 ii complete this set to a basis of Rn . It follows that ii nm , y 11 x WBx , ,0 i z, and By 11 yW , ii are eigenvectors associated with 1 . The r vectors 1 i ,i x WB x are igenvec- tors associated with 1 . When the parameters satisfy 11 , we can obtain the following corollary from Theorem 2.1. Corollary 2.2. Let 11 . Then the matrix 1 M A has one eigenvalue which given by 1 with algebraic multiplicity n + r. The remaining m − r eigenvalues sat- isfy the relation 1, where µ are positive generalized eigenvalues of 1T B WBuFu . Theorem 2.3. The matrix 1 M A has two distinct ei- genvalues, given by 11 and 21 , with the algebraic multiplicities n and r, respectively. The remaining m − r eigenvalues lie in the interval 0,10 ,or1,00 . Proof: From Theorem 2.1 we obtain that the matrix 1 M A has two distinct eigenvalues, given by 11 and 21 , with the algebraic multiplicities n and r, respectively. Taking inner product of (5) with u, we can obtain that the remaining m − r eigenvalues satisfy 1 1 , ,, T T BW Buu F uuBW Buu , (6) where , denotes the standard Euclidean inner prod- uct, u null(F) and u null(B). By (6), we have that the remaining m − r eigenvalues lie in interval Copyright © 2011 SciRes. AJCM 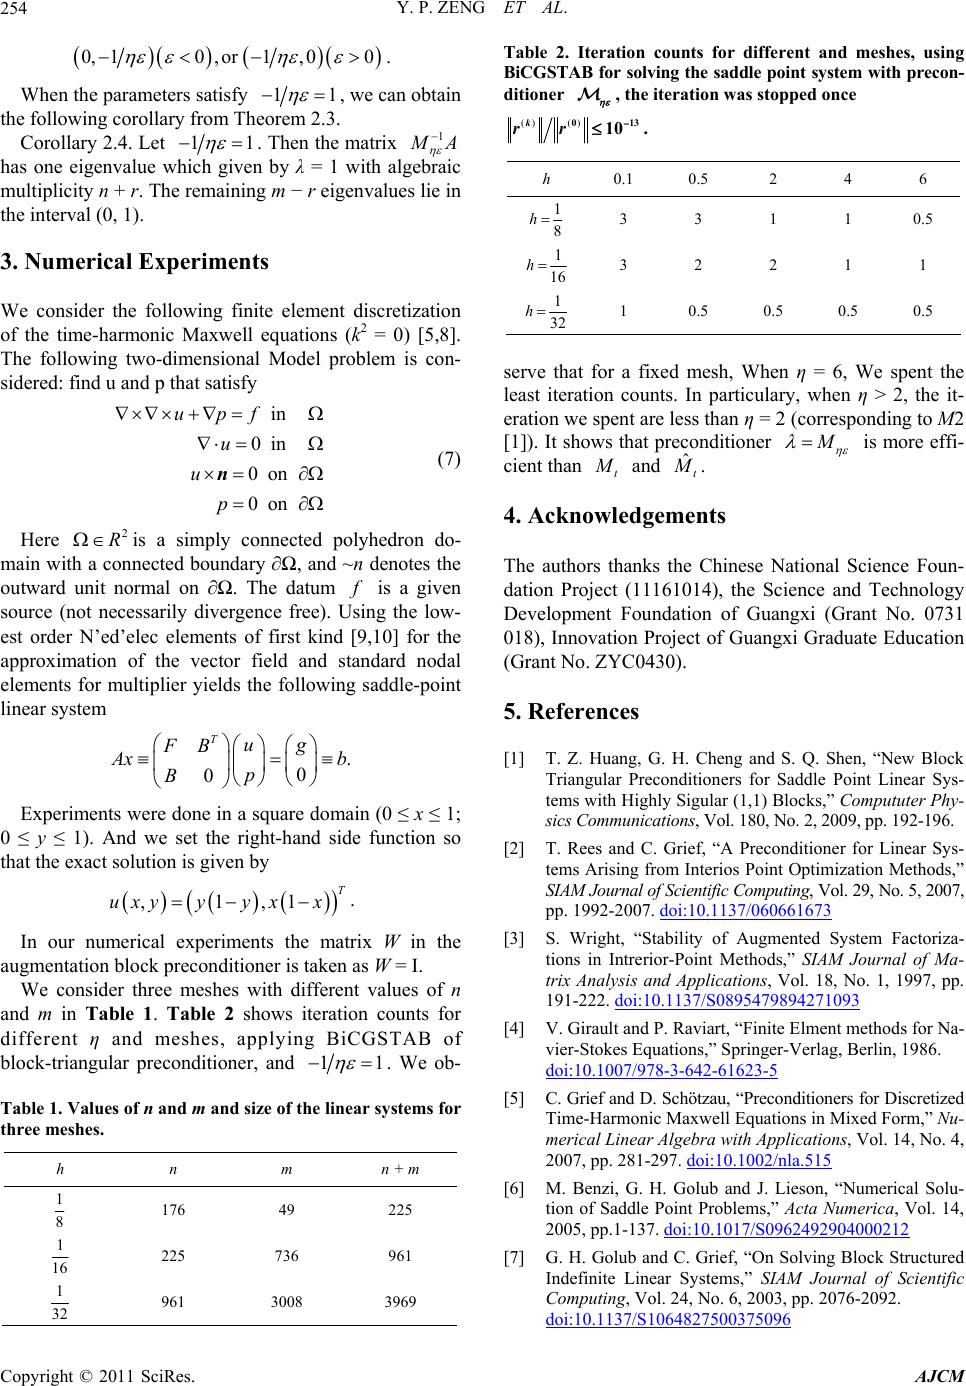 Y. P. ZENG ET AL. 254 0,10 ,or1,00 . When the parameters satisfy 11 , we can obtain the following corollary from Theorem 2.3. Corollary 2.4. Let 11 . Then the matrix 1 M A has one eigenvalue which given by λ = 1 with algebraic multiplicity n + r. The remaining m − r eigenvalues lie in the interval (0, 1). 3. Numerical Experiments We consider the following finite element discretization of the time-harmonic Maxwell equations (k2 = 0) [5,8]. The following two-dimensional Model problem is con- sidered: find u and p that satisfy in 0in 0on 0on upf u u p n (7) Here is a simply connected polyhedron do- main with a connected boundary ∂Ω, and ~n denotes the outward unit normal on ∂Ω. The datum 2 R f is a given source (not necessarily divergence free). Using the low- est order N’ed’elec elements of first kind [9,10] for the approximation of the vector field and standard nodal elements for multiplier yields the following saddle-point linear system . 0 0 Tug FB A x p B b Experiments were done in a square domain (0 ≤ x ≤ 1; 0 ≤ y ≤ 1). And we set the right-hand side function so that the exact solution is given by ,1,1 T uxyyyxx . In our numerical experiments the matrix W in the augmentation block preconditioner is taken as W = I. We consider three meshes with different values of n and m in Table 1. Table 2 shows iteration counts for different η and meshes, applying BiCGSTAB of block-triangular preconditioner, and 11 . We ob- Table 1. Values of n and m and size of the linear systems for three meshes. h n m n + m 1 8 176 49 225 1 16 225 736 961 1 32 961 3008 3969 Table 2. Iteration counts for different and meshes, using BiCGSTAB for solving the saddle point system with precon- ditioner , the iteration was stopped once () 013k rr ()10 . h 0.1 0.5 2 4 6 1 8 h 3 3 1 1 0.5 1 16 h3 2 2 1 1 1 32 h1 0.5 0.5 0.5 0.5 serve that for a fixed mesh, When η = 6, We spent the least iteration counts. In particulary, when η > 2, the it- eration we spent are less than η = 2 (corresponding to M2 [1]). It shows that preconditioner M is more effi- cient than t M and ˆt M . 4. Acknowledgements The authors thanks the Chinese National Science Foun- dation Project (11161014), the Science and Technology Development Foundation of Guangxi (Grant No. 0731 018), Innovation Project of Guangxi Graduate Education (Grant No. ZYC0430). 5. References [1] T. Z. Huang, G. H. Cheng and S. Q. Shen, “New Block Triangular Preconditioners for Saddle Point Linear Sys- tems with Highly Sigular (1,1) Blocks,” Compututer Phy- sics Communications, Vol. 180, No. 2, 2009, pp. 192-196. [2] T. Rees and C. Grief, “A Preconditioner for Linear Sys- tems Arising from Interios Point Optimization Methods,” SIAM Journal of Scientific Computing, Vol. 29, No. 5, 2007, pp. 1992-2007. doi:10.1137/060661673 [3] S. Wright, “Stability of Augmented System Factoriza- tions in Intrerior-Point Methods,” SIAM Journal of Ma- trix Analysis and Applications, Vol. 18, No. 1, 1997, pp. 191-222. doi:10.1137/S0895479894271093 [4] V. Girault and P. Raviart, “Finite Elment methods for Na- vier-Stokes Equations,” Springer-Verlag, Berlin, 1986. doi:10.1007/978-3-642-61623-5 [5] C. Grief and D. Schötzau, “Preconditioners for Discretized Time-Harmonic Maxwell Equations in Mixed Form,” Nu- merical Linear Algebra with Applications, Vol. 14, No. 4, 2007, pp. 281-297. doi:10.1002/nla.515 [6] M. Benzi, G. H. Golub and J. Lieson, “Numerical Solu- tion of Saddle Point Problems,” Acta Numerica, Vol. 14, 2005, pp.1-137. doi:10.1017/S0962492904000212 [7] G. H. Golub and C. Grief, “On Solving Block Structured Indefinite Linear Systems,” SIAM Journal of Scientific Computing, Vol. 24, No. 6, 2003, pp. 2076-2092. doi:10.1137/S1064827500375096 Copyright © 2011 SciRes. AJCM  Y. P. ZENG ET AL. Copyright © 2011 SciRes. AJCM 255 [8] C. Grief and D. Schötzau, “Preconditioners for Saddle Point Linear Systems with Highly Singular (1,1) Blocks,” Electronic Transactions on Numerical Analysis, Vol. 22, 2006, pp. 114-121. [9] P. Monk, “Finite Elements for Maxwell’s Quations,” Ox- frod University Press, New York, 2003. [10] J. C. Nédélec, “A New Family of Mixed Finite Elements in ℝ3,” Numerische Mathematik, Vol. 50, No. 1, 1986, pp. 57-81. doi:10.1007/BF01389668 |