

Paper Menu >>
Journal Menu >>
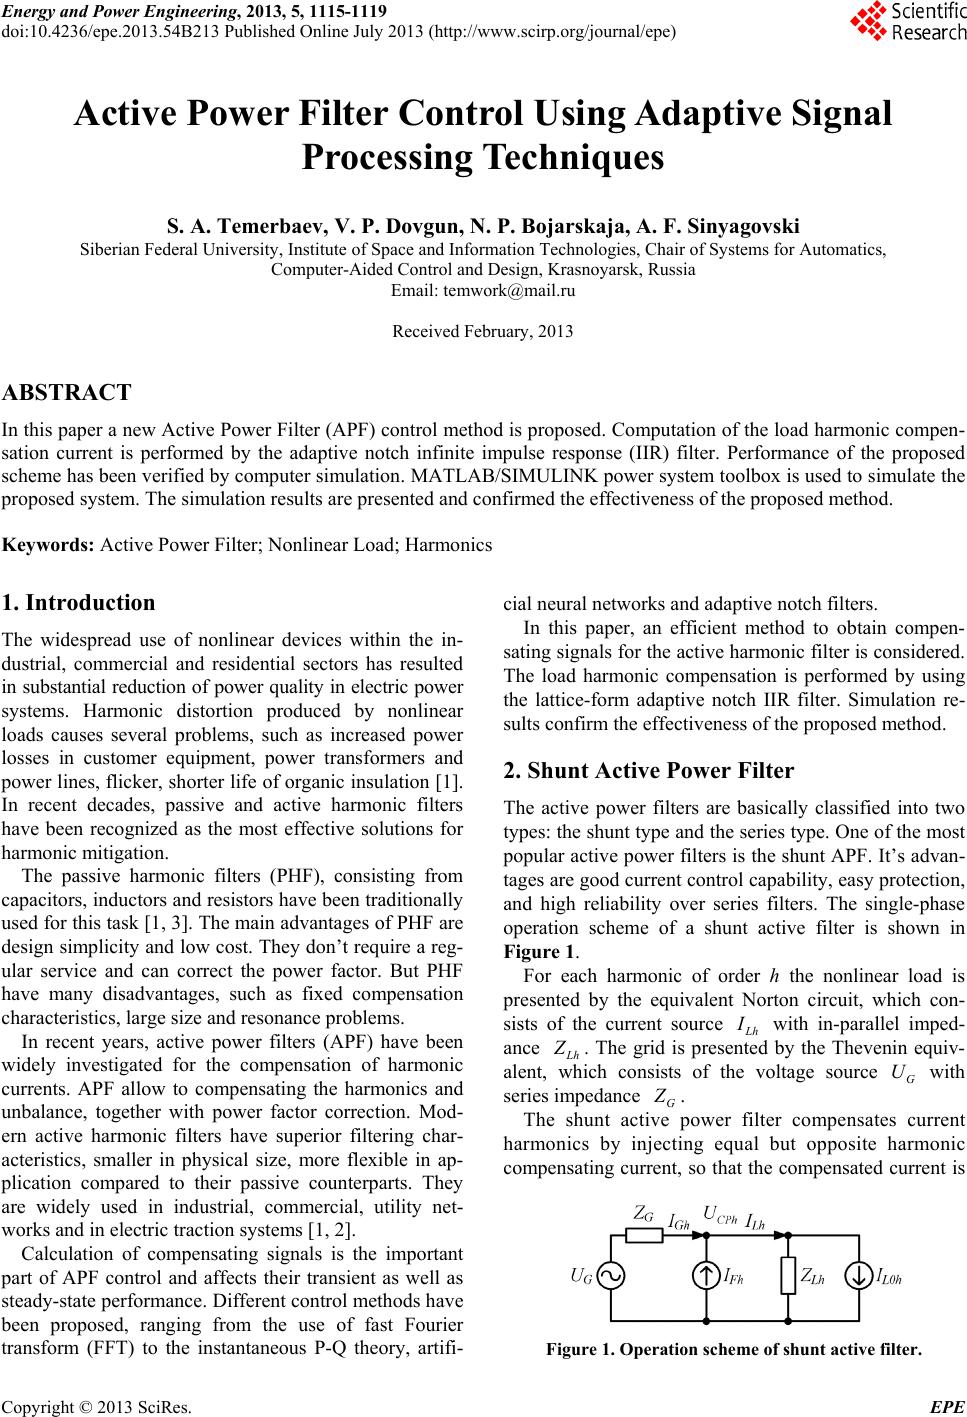 Energy and Power Engineering, 2013, 5, 1115-1119 doi:10.4236/epe.2013.54B213 Published Online July 2013 (http://www.scirp.org/journal/epe) Active Power Filter Control Using Adaptive Signal Pr ocessing Techniques S. A. Temerbaev, V. P. Dovgun, N. P. Bojarskaja, A. F. Sinyagovski Siberian Federal University, Institute of Space and Information Technologies, Chair of Systems for Automatics, Computer-Aided Control and Design, Krasnoyarsk, Russia Email: [email protected] Received February, 2013 ABSTRACT In this paper a new Active Power Filter (APF) control method is proposed . Computation of the load harmonic compen- sation current is performed by the adaptive notch infinite impulse response (IIR) filter. Performance of the proposed scheme has been verified by computer simulation. MATLAB/SIMULINK power system toolbox is used to simulate the proposed system. The simulation results are presented and confirmed the effectiveness of the proposed method. Keywords: Active Power Filter; Nonlinear Load; Harmonics 1. Introduction The widespread use of nonlinear devices within the in- dustrial, commercial and residential sectors has resulted in substantial reduction of power quality in electric power systems. Harmonic distortion produced by nonlinear loads causes several problems, such as increased power losses in customer equipment, power transformers and power lines, flicker, shorter life of organic insulation [1]. In recent decades, passive and active harmonic filters have been recognized as the most effective solutions for harmonic mitigation. The passive harmonic filters (PHF), consisting from capacitors, inductors and resistors have been trad itionally used for this task [1, 3]. The main advantages of PHF are design simplicity and low cost. Th ey don’t require a reg- ular service and can correct the power factor. But PHF have many disadvantages, such as fixed compensation characteristics, large size and resonance problems. In recent years, active power filters (APF) have been widely investigated for the compensation of harmonic currents. APF allow to compensating the harmonics and unbalance, together with power factor correction. Mod- ern active harmonic filters have superior filtering char- acteristics, smaller in physical size, more flexible in ap- plication compared to their passive counterparts. They are widely used in industrial, commercial, utility net- works and in electric traction systems [1, 2]. Calculation of compensating signals is the important part of APF control and affects their transient as well as steady-state performance. Different control methods have been proposed, ranging from the use of fast Fourier transform (FFT) to the instantaneous P-Q theory, artifi- cial neural networks and adaptive notch filters. In this paper, an efficient method to obtain compen- sating signals for the active harmonic filter is considered. The load harmonic compensation is performed by using the lattice-form adaptive notch IIR filter. Simulation re- sults confirm the effectiveness of the proposed method. 2. Shunt Active Power Filter The active power filters are basically classified into two types: the shunt type and the series type. One of the most popular active power filters is the shun t APF. It’s advan- tages are good current con trol capability, easy p rotection, and high reliability over series filters. The single-phase operation scheme of a shunt active filter is shown in Figure 1. For each harmonic of order h the nonlinear load is presented by the equivalent Norton circuit, which con- sists of the current source L h I with in-parallel imped- ance L h Z . The grid is presented by the Thevenin equiv- alent, which consists of the voltage source with series impedance G U G Z . The shunt active power filter compensates current harmonics by injecting equal but opposite harmonic compensating current, so that the compensated current is Figure 1. Operation scheme of shunt active filter. Copyright © 2013 SciRes. EPE 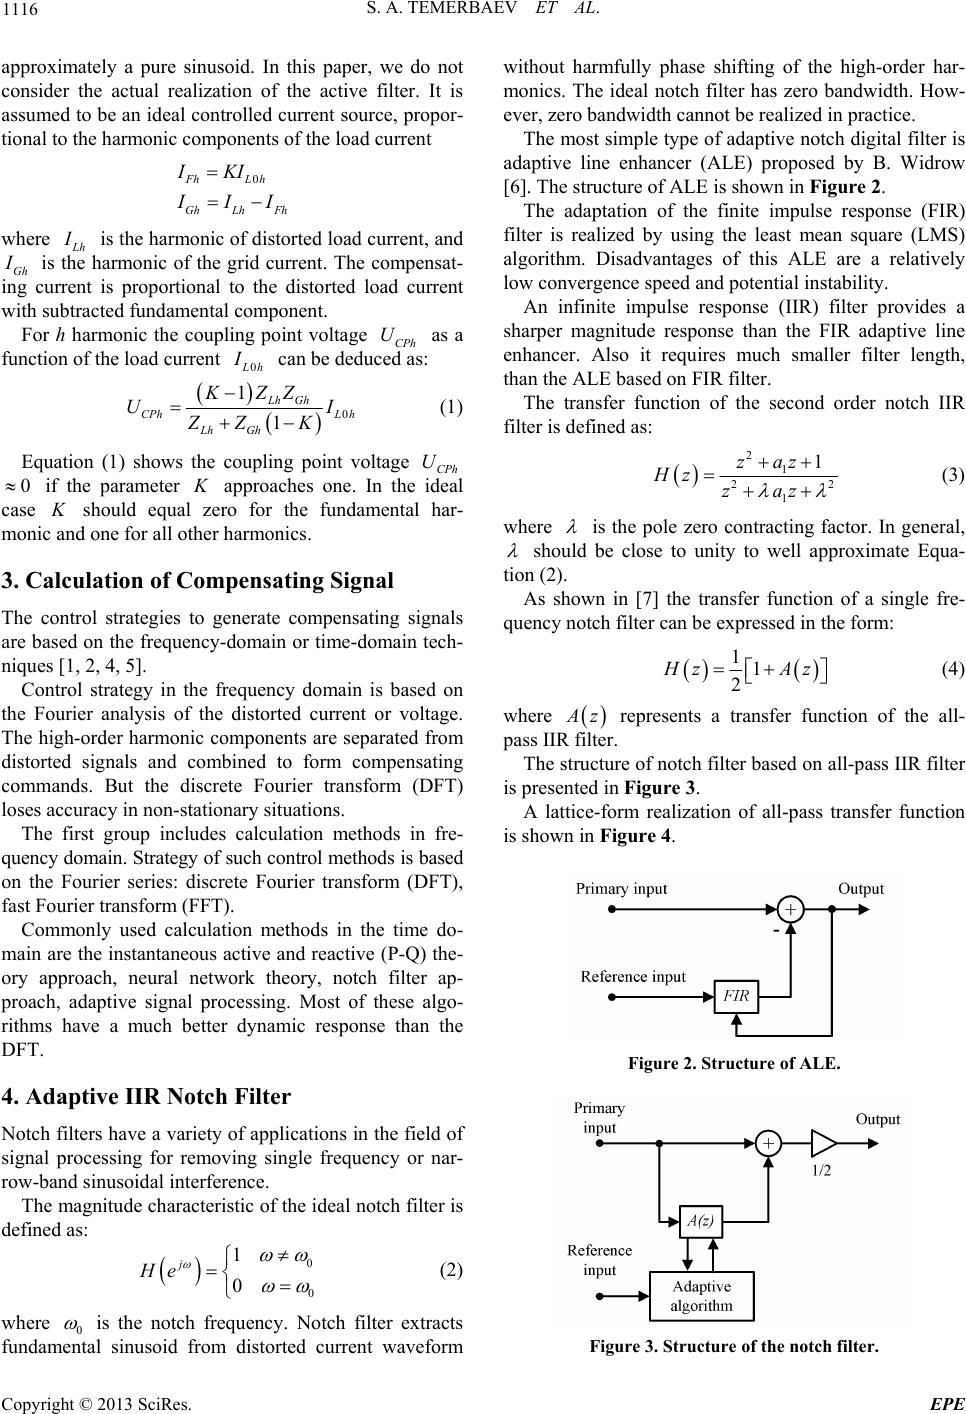 S. A. TEMERBAEV ET AL. 1116 approximately a pure sinusoid. In this paper, we do not consider the actual realization of the active filter. It is assumed to be an ideal controlled current source, propor- tional to the harmonic components of the load current 0FhL h GhLh Fh IKI I II where L h I is the harmonic of distorted load current, and Gh I is the harmonic of the grid current. The compensat- ing current is proportional to the distorted load current with subtracted fundamental component. For h harmonic the coupling point voltage CPh as a function of the l oad cu rrent U 0 L h I can be deduced as: 0 1 1 Lh Gh CPhL h Lh Gh KZZ UI ZZ K (1) Equation (1) shows the coupling point voltage CPh if the parameter U 0 K approaches one. In the ideal case K should equal zero for the fundamental har- monic and one for all other harmonics. 3. Calculation of Compensating Signal The control strategies to generate compensating signals are based on the frequency-domain or time-domain tech- niques [1, 2, 4, 5]. Control strategy in the frequency domain is based on the Fourier analysis of the distorted current or voltage. The high-order harmonic components are separated from distorted signals and combined to form compensating commands. But the discrete Fourier transform (DFT) loses accuracy in non-stationary situations. The first group includes calculation methods in fre- quency domain. Strategy of such control methods is based on the Fourier series: discrete Fourier transform (DFT), fast Fourier transform (FFT). Commonly used calculation methods in the time do- main are the instantaneou s active and reactive (P-Q) the- ory approach, neural network theory, notch filter ap- proach, adaptive signal processing. Most of these algo- rithms have a much better dynamic response than the DFT. 4. Adaptive IIR Notch Filter Notch filters have a variety of applications in the field of signal processing for removing single frequency or nar- row-band sinusoidal interference. The magnitude characteristic of the ideal notch filter is defined as: 0 0 1 0 j He (2) where 0 is the notch frequency. Notch filter extracts fundamental sinusoid from distorted current waveform without harmfully phase shifting of the high-order har- monics. The ideal notch filter has zero bandwidth. How- ever, zero bandwidth cannot be realized in practice. The most simple type of adaptive n otch digital filter is adaptive line enhancer (ALE) proposed by B. Widrow [6]. The structure of ALE is shown in Figure 2. The adaptation of the finite impulse response (FIR) filter is realized by using the least mean square (LMS) algorithm. Disadvantages of this ALE are a relatively low convergence speed and potential instability. An infinite impulse response (IIR) filter provides a sharper magnitude response than the FIR adaptive line enhancer. Also it requires much smaller filter length, than the ALE based on FIR filter. The transfer function of the second order notch IIR filter is defined as: 21 2 1 1zaz Hz zaz 2 (3) where is the pole zero contracting factor. In general, should be close to unity to well approximate Equa- tion (2). As shown in [7] the transfer function of a single fre- quency notch filter can be expressed in the form: 11 2 H zA z (4) where A z represents a transfer function of the all- pass IIR filter. The structure of notch filter based on all-pass IIR filter is presented in Figure 3. A lattice-form realization of all-pass transfer function is shown in Figure 4. Figure 2. Structure of ALE. Figure 3. Structure of the notch filter. Copyright © 2013 SciRes. EPE 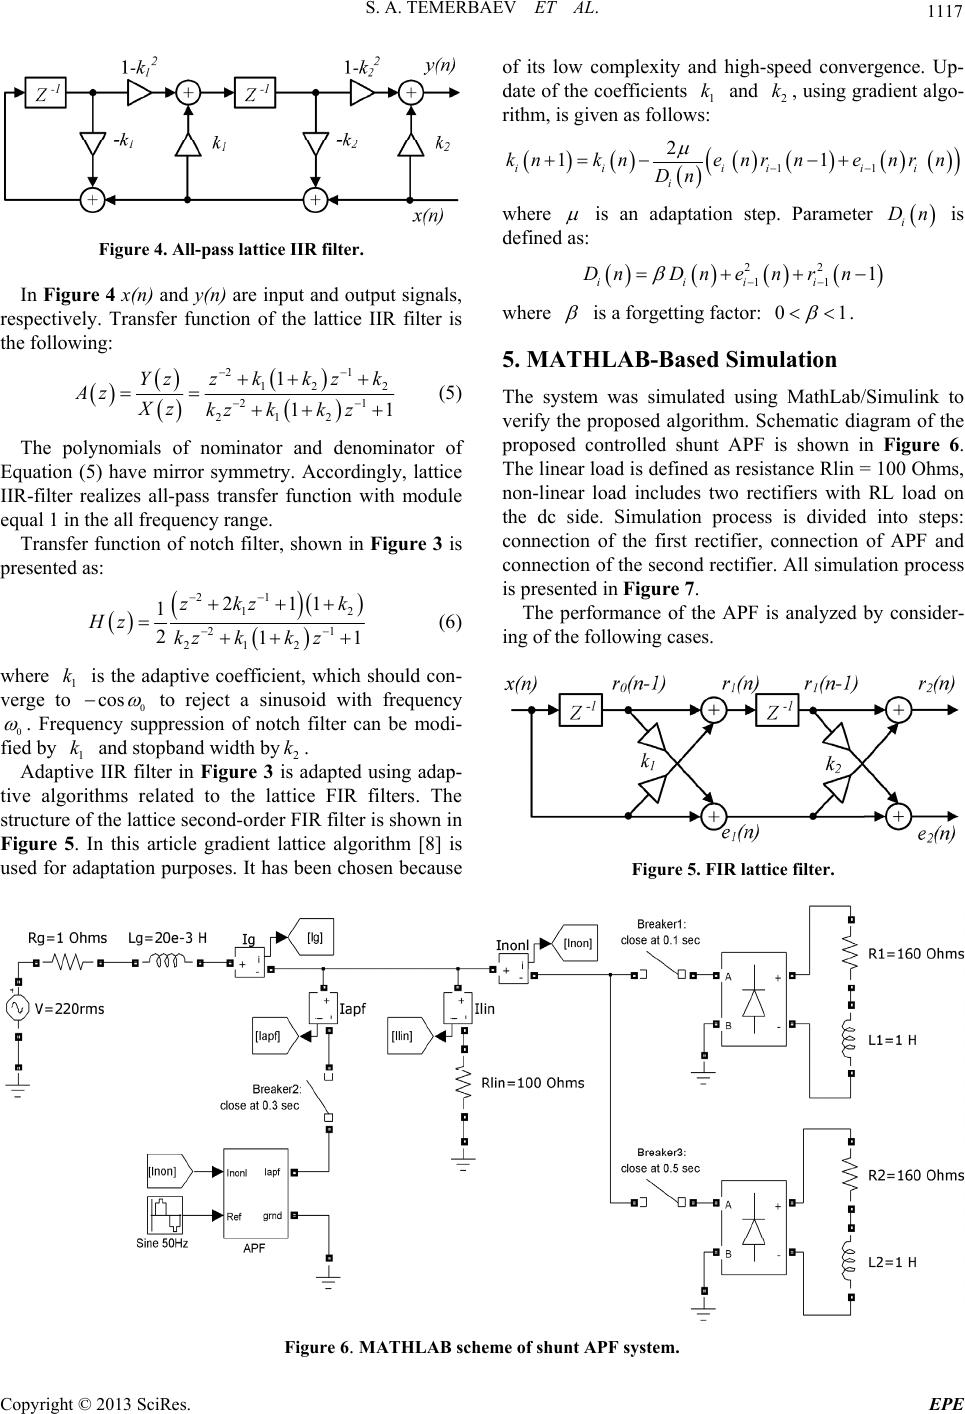 S. A. TEMERBAEV ET AL. Copyright © 2013 SciRes. EPE 1117 of its low complexity and high-speed convergence. Up- date of the coefficients 1 and , using gradient algo- rithm, is given as follows: k2 k 11 2 11 iiii ii i knknenr nenrn Dn is an adaptation step. Parameter i Dn where is defined: as Figure 4. All-pass lattice IIR filter. 22 11 1 iiii nDn en rn D In Figure 4 x(n) and y(n) are input and output signals, respectively. Transfer function of the lattice IIR filter is the following: is a forgetting factor: 01 . where 5. MATHLAB-Based Simulation b/Simulink to APF is analyzed by consider- in 21 12 21 212 1 11 Yzzkk zk Az Xz kzkk z 2 (5) The system was simulated using MathLa verify the proposed algorithm. Schematic diagram of the proposed controlled shunt APF is shown in Figure 6. The linear load is defined as resistance Rlin = 100 Ohms, non-linear load includes two rectifiers with RL load on the dc side. Simulation process is divided into steps: connection of the first rectifier, connection of APF and connection of the second rectifier. All simulation process is presented in Figure 7. The performance of the The polynomials of nominator and denominator of Equation (5) have mirror symmetry. Accordingly, lattice IIR-filter realizes all-pass transfer function with module equal 1 in the all frequency range. Transfer function of notch filter, shown in Figure 3 is presented as: 21 1 2 212 211 1 211 zkz k Hz kzkk z 2 1 (6) g of the following cases. where 1 is the adaptive coefficient, which should con- verge to 0 kcos to reject a sinusoid with frequency 0 . Frequency suppression of notch filter can be modi- fied by and stopband widt h by. 1 2 Adaptive IIR filter in Figure 3 is adapted using adap- tive algorithms related to the lattice FIR filters. The structure of the lattice second-o rder FIR filter is shown in Figure 5. In this article gradient lattice algorithm [8] is used for adaptation purposes. It has been chosen because k k Figure 5. FIR lattice filter. Figure 6. MATHLAB scheme of shunt APF system. 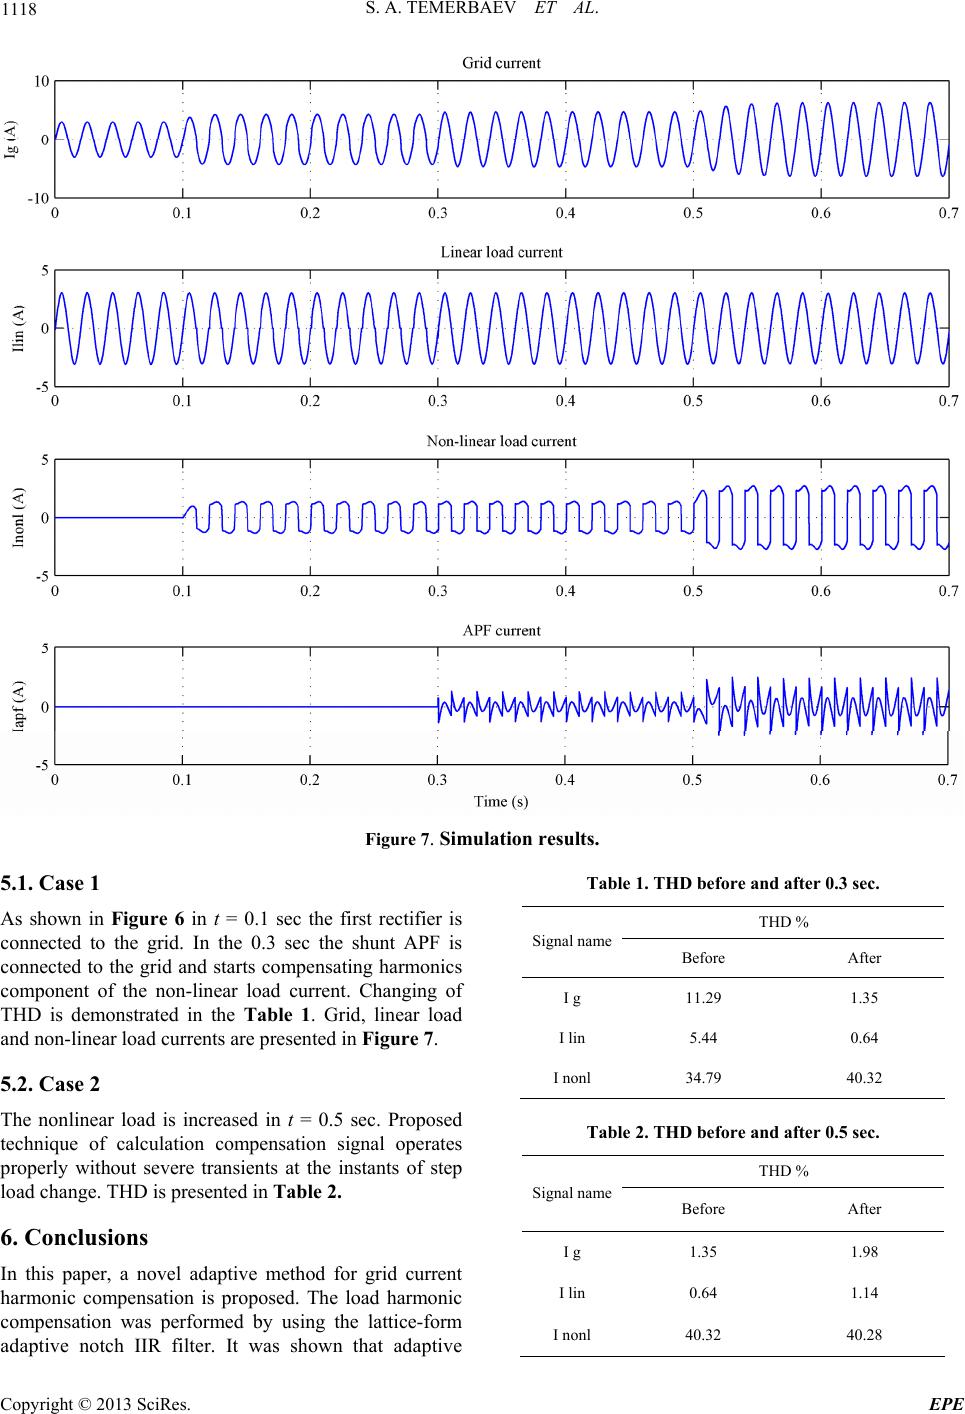 S. A. TEMERBAEV ET AL. 1118 Figure 7. Simulation results. .1. Case 1 Figure 6 in t = 0.1 sec the first rectifier is 5.2. Case 2 load is increased in t = 0.5 sec. Proposed 6. Conclusions el adaptive method for grid current Table 1. THD before and after 0.3 sec. 5 As shown in connected to the grid. In the 0.3 sec the shunt APF is connected to the grid and starts compensating harmonics component of the non-linear load current. Changing of THD is demonstrated in the Table 1. Grid, linear load and non-linear load currents are presented in Figure 7. The nonlinear technique of calculation compensation signal operates properly without severe transients at the instants of step load chang e. THD is presented in Table 2. In this paper, a nov harmonic compensation is proposed. The load harmonic compensation was performed by using the lattice-form adaptive notch IIR filter. It was shown that adaptive THD % Signal nameBefore After I g 11.29 1.35 I lin 5.44 0.64 I nonl 34.79 40.32 Table 2. THD before and after 0.5 sec. THD % Signal nameBefore After I g 1.35 1.98 I lin 0.64 1.14 I nonl 40.32 40.28 Copyright © 2013 SciRes. EPE  S. A. TEMERBAEV ET AL. 1119 notch filtetive har- monic filter for the sake of hic mitigation prooach does not neey training o notch filter. Performathe proposed l system is verified by computer simulation. MATLAB/SIM LINK power system tis used to sime the pro- posed system. The ults presented showing the effectiveness of the proposed method. REFERENCES [1] H. Akagiings of th IEEE, Vol. 93, No. 12, 2005,-2141. 9/JPROC.2005.859603 r can be successfully employed in ac armon d an. The f the posed apprnce of contro U- oolbox ulat simulation resare , “Active Harmonic Filters,” Proceede pp. 2128 doi:10.110 [2] B. Singh, K. Al-Hnd A. Chandreview Ace Filters for Power Quality Improvent,” IEEE Trans. on Industria Vol. 46, No. 5, 1999, pp. 960-971. doi:10.1109/41.793345 addad aa, “A R of tiv me l Electronics, [3] J. Das, “Passive Filters – Potentialities and mitations IEEE Transactions, Vol. 40, No. Li,” tions on Industry Applica 1, 2004, pp. 232-241. doi:10.1109/TIA.2003.821666 [4] L. Asiminoaei, F. Blaabjerg and S. Hansen, “Detection is Key,” IEEE Industry Applications Magazine,2007, pp. 22-33. [5] “A Single-phase DG Generation Unit with Shunt Active Power Filter Capability by Adaptive Neural Filtering,” IEEE Transactions on Industrial Electronics, Vol. 55, No. 5, 2008, pp. 2093-2110. doi:10.1109/TIE.2008.918642 [6] B. Widrow and S. P. Stearns, “Adaptive Signal Process- ing of Englewood Cliffs,” NJ: Prentice-Hall, Inc. 1985. [7] P. A. Regalia, S. K. Mitra and P. P. Vaidyanathan, “The Digital All-pass Filter: A Versatile Signal Processing Building Block,” Proceedings of IEEE, Vol. 76, No. 1, 1998, pp. 19-37. doi:10.1109/5.3286 [8] Hodkiss and J. F. Presley, “Adaptive Tracking of Multi- ple Sinusoids Whose Power Levels are Widely Sepa- rated,” IEEE Transactions on Circuits and Systems, Vol. CAS-28, No. 6, 1981, pp. 550-561. Copyright © 2013 SciRes. EPE |