Paper Menu >>
Journal Menu >>
 Engineering, 2013, 5, 85-89 http://dx.doi.org/10.4236/eng.2013.510B017 Published Online October 2013 (http://www.scirp.org/journal/eng) Copyright © 2013 SciRes. ENG Modeling and Simulation of Lapar o scopic Tools for Autonomously Positioning Lapar oscope in Lapar oscopic Surgery S. M. Megahed, A. A. Balbola Mechanical Design & Production Engineering Department, Faculty of Engineering, Giza, Egypt Email: [email protected], [email protected]. eg Received December 2012 ABSTRACT In laparoscopic surgery, the surgeons are equipped with the suitable tools for the surgery, while the laparoscope is used to capture the operation environment and displays it on a monitor. This paper presents the mathematical kinematic posi- tion modeling of the laparoscopic tools used for autonomous positioning of a laparoscope in such operations. These models are obtained using Denavit-Hartenberg (D-H) Notations and Homogenous Transformation Matrix (HTM). The laparoscopic tools are considered as six degrees of freedom (DOF) mechanisms while the laparoscope has four DOF. The 3D loop closure equation is used to obtain the laparoscope kinematic position models in terms of those of the lapa- roscopic tools. These models are used to simulate and align the laparoscope camera with the surgeon’s laparoscopic Tools Center Points (TCP). The obtained results show the smooth positioning of the laparoscope camera for better visu- alization of laparoscopic surgery environments. Keywords: Laparosc opi c Surgery; Homogeno us T ransformation Matrix; Denavit-Hartenberg Notations 1. Introduction In laparoscopic surgery, two main problems challenge the surgeons. The first is increasing field of vision capac- ity and controlling system to carry out complex opera- tional gestures without using high body mobility. The second is the tools flexibilities inside the human body to do more complex in vivo healthcare operations. Now most Laparoscopic Surgeries are done using 6 DOF la- paroscopic tools to increase their flexibility inside the human body. Surgeons visualize the surgery environment using a laparoscope. Any wrong movement of the lapa- roscope interrupts the operation and the surgeon stops until controlling the laparoscope focus again on the oper- ation area. Many researches are done for autonomously positioning the laparoscope instead of the laparoscope manual positioning by an operator. Halin et al. [1] de- veloped a novel a laparoscope which detect and to follow the movements of the surgeon’s head. Terry et al. [2] built a port camera integrated with the laparoscopic tool. Weede et al. [3] designed an endoscopic guidance system to autonomously align the laparoscope with the TCP of the surgeon’s instruments which uses the information on the movements of the instruments from former interven- tions to predict the laparoscope motion. Terry et al. also [4] designed, built, and tested a novel single-port access laparoscopic surgery specific camera system (magnet camera). Xu et al. [5] derives the analytical solution for a 5-DOF manipulator to follow a given trajectory. In this paper, the direct and inverse kinematic position models of two laparoscopic tools and one laparoscope are derived for autonomous positioning of the laparos- cope camera. After an introduction, the paper is orga- nized in three main sections. In Section 1, the kinematic position models of the two 6 DOF laparoscopic tools and one laparoscope are presented. In Section 2, the laparos- cope models are developed as function of the parameters of the two laparoscopic tools. The obtained simulation results using the developed models are presented in Sec- tion 3. 2. Kinematic Modeling of 6 DOF Laparoscopic Tools In laparoscopic surgery, Surgeons use two 6 DOF lapa- roscopic tools (right & left) to carry out complex opera- tions. The four Denavit-Hartenberg (D-H) parameters (θi, ri, ai, and αi for i = 1, 2 6) are used for generating the elementary HTM’s (Ti,i+1) of the laparoscopic tools (see Figure 1, and Table 1) [6]. By substituting the D-H par ameters in Ta ble 1 into (1) the 6 elementary HTM’s (Ti,i+1) for i = 1, 2 6 are de- termined which are used in (2) to obtain the generalized HTM (T0,7). 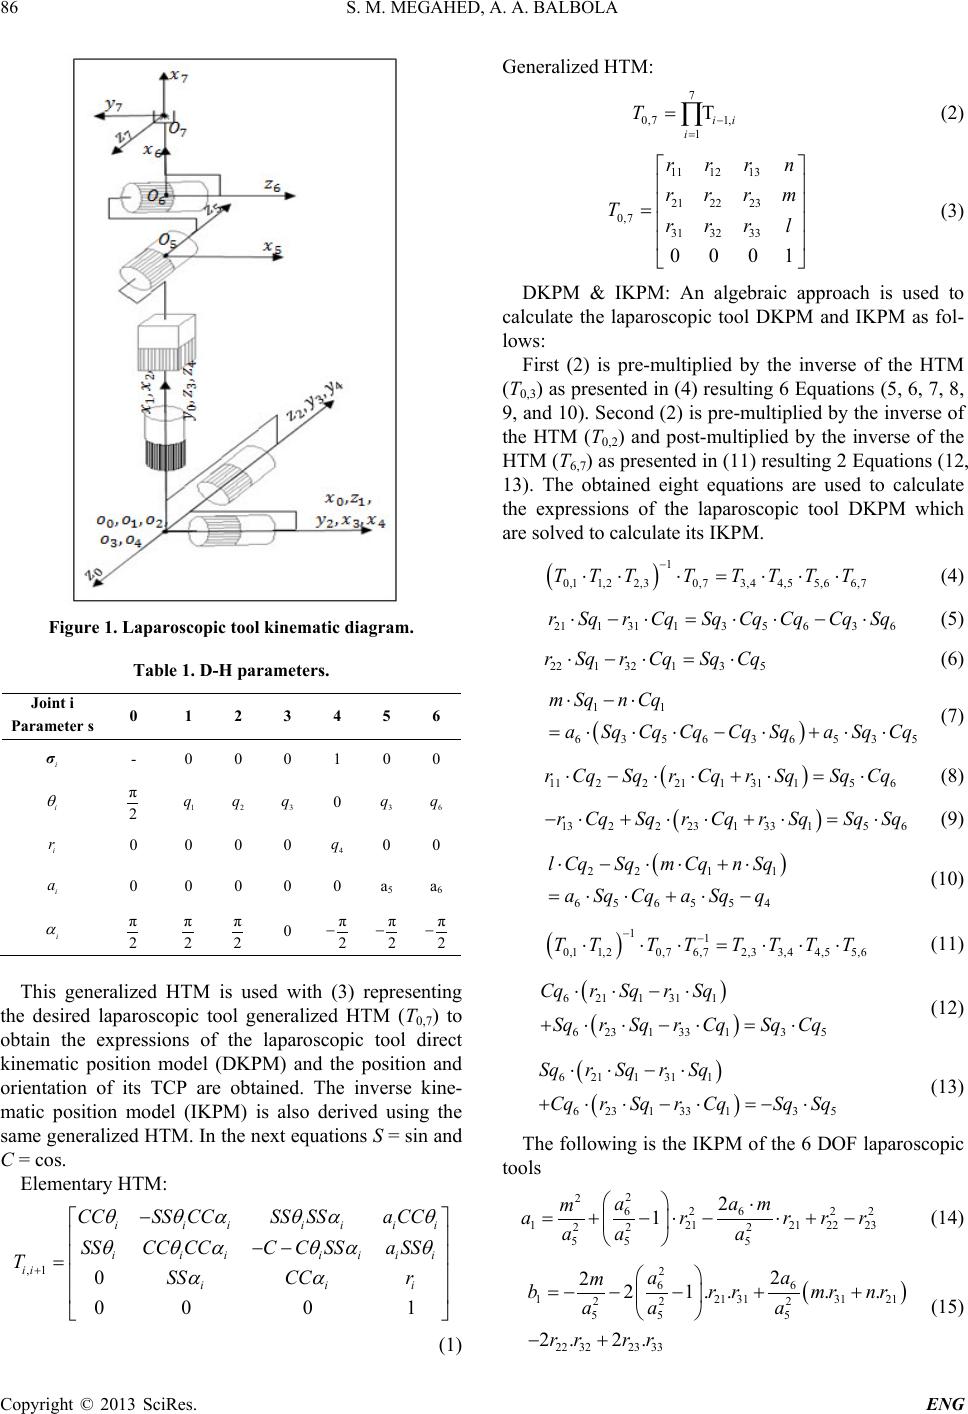 S. M. MEGAHED, A. A. BALBOLA Copyright © 2013 SciRes. ENG 86 Figure 1. Laparoscopic tool kinematic diagram. Table 1. D-H parameters. Joint i 0 1 2 3 4 5 6 Parameter s i σ - 0 0 0 1 0 0 i θ π 2 1 q 2 q 3 q 0 3 q 6 q i r 0 0 0 0 4 q 0 0 i a 0 0 0 0 0 a5 a6 i α π 2 π 2 π 2 0 π 2 − π 2 − π 2 − This generalized HTM is used with (3) representing the desired laparoscopic tool generalized HTM (T0,7) to obtain the expressions of the laparoscopic tool direct kinematic position model (DKPM) and the position and orientation of its TCP are obtained. The inverse kine- matic position model (IKPM) is also derived using the same generalized HTM. In the next equations S = sin and C = cos. Elementary HTM: ,1 0 0001 iiiiii i iiii iii ii i ii CCSSCCSSSSa CC SSCCCCCCSSa SS TSSCC r θθ αθαθ θθαθαθ αα + − −− = (1) Generalized HTM: 7 0,7 1, 1 T ii i T − = =∏ (2) 11 1213 21 2223 0,7 31 3233 0001 rrrn rr rm Trrr l = (3) DKPM & IKPM: An algebraic approach is used to calculate the laparoscopic tool DKPM and IKPM as fol- lows: First (2) is pre-multiplied by the inverse of the HTM (T0,3) as presented in (4) resulting 6 Equations (5, 6, 7, 8, 9, and 10). Second (2) is pre-multiplied by the inverse of the HTM (T0,2) and post-multiplied by the inverse of the HTM (T6,7) as presented in (11) resulting 2 Equations (12, 13). The obtained eight equations are used to calculate the expressions of the laparoscopic tool DKPM which are solved to calculate its IKPM. ( ) 1 0,11,2 2,30,73,4 4,55,6 6,7 TTTT TTTT − ⋅⋅ ⋅⋅⋅⋅= (4) 21131135636 rSqrCqSqCq CqCqSq−= −⋅ ⋅⋅⋅⋅ (5) 221 32135 rSqrCqSq Cq⋅⋅ ⋅−= (6) ( ) 11 63 5 63653 5 mSqn Cq aSq CqCqCqSqaSq Cq⋅ ⋅⋅ ⋅ −⋅ =+ ⋅− ⋅⋅ (7) ( ) 1122 21131156 rCqSqrCqrSqSq Cq− +=⋅⋅⋅ ⋅⋅ (8) ( ) 1322231 33156 rCqSqrCqrSqSq Sq−++ =⋅⋅⋅ ⋅⋅ (9) ( ) 221 1 6 565 54 lCqSqm CqnSq aSq CqaSqq −+ = ⋅⋅⋅ ⋅ +⋅ −⋅⋅ (10) ( ) 11 0,11,20,7 6,72,33,4 4,55,6 TTTT TTTT −− ⋅⋅⋅=⋅ ⋅⋅ (11) ( ) ( ) 621 131 1 6231 33135 CqrSqr Sq SqrSqrCqSq Cq ⋅⋅ ⋅ ⋅ =⋅−⋅⋅ − + (12) ( ) ( ) 621 131 1 6231 33135 SqrSqrSq CqrSqrCqSq Sq − + −=− ⋅⋅ ⋅ ⋅⋅ ⋅⋅ (13) The following is the IK PM of the 6 DOF laparoscopic tools 2 22 22 66 12121 2223 22 2 55 5 2 1 a am m ar rrr aa a =+− −+ ⋅ −⋅ ⋅ (14) ( ) 2 66 121 313121 22 2 55 5 22 3223 33 2 221. ... 2. 2. aa m br rmrnr aa a rr rr =−− −++ −+ (15) 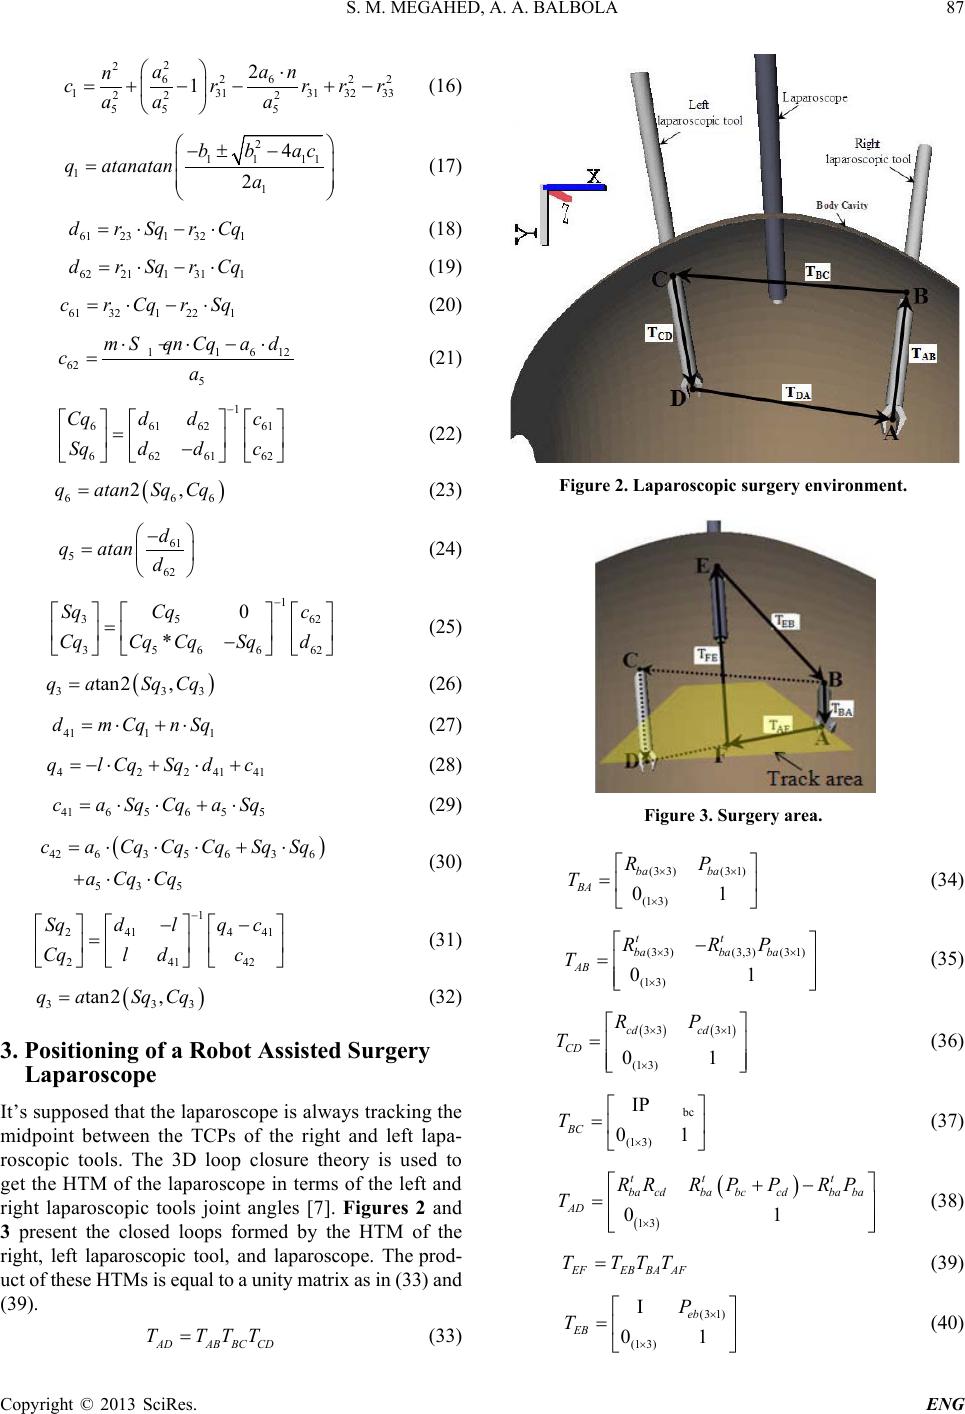 S. M. MEGAHED, A. A. BALBOLA Copyright © 2013 SciRes. ENG 87 2 22 22 66 13131 32 33 22 2 55 5 2 1 a an n cr rrr aa a = +−−+− ⋅ (16) 2 1 111 11 4 2 b bac q atanatana −± − = (17) 61231321 drSqr Cq−⋅⋅= (18) 62211 311 drSqrCq−⋅⋅= (19) 61321 221 cr CqrSq−⋅⋅= (20) 116 12 62 5 mSqnCqad ca ⋅⋅ ⋅ −− = (21 ) 1 661 6261 662 6162 Cqd dc Sqd dc − = − (22) ( ) 6 66 2,qatanSq Cq= (23) 61 562 d qatan d − = (24) 1 3 562 35 6662 0 * Sq Cqc CqCq CqSqd − = − (25) ( ) 3 33 tan2 ,qaSq Cq= (26) 4111 dm CqnSq⋅+⋅= (27) 422 4141 ql CqSqdc⋅++⋅= − (28) 4165655 caSq CqaSq⋅⋅ ⋅= + (29) ( ) 4263563 6 535 caCq Cq CqSqSq a Cq Cq = + ⋅+ ⋅ ⋅⋅⋅ ⋅ (30) 1 2414 41 241 42 Sqdlq c Cqldc − −− = (3 1) ( ) 3 33 tan2 ,qaSq Cq= (32) 3. Positioning of a Robot Assisted Surgery Laparoscope It’s supposed that the laparoscope is always tracking the midpoint between the TCPs of the right and left lapa- roscopic tools. The 3D loop closure theory is used to get the HTM of the laparoscope in terms of the left and righ t laparoscopic tools joint angles [7]. Figures 2 and 3 present the closed loops formed by the HTM of the right, left laparoscopic tool, and laparoscope. The prod- uct of these HTMs is equal to a unity matrix as in (33) and (39). ADAB BC CD T TTT= (33) Figure 2. Laparoscopic surgery environment. Figure 3. Surgery area. (33)(3 1) (1 3) 01 ba ba BA RP T ×× × = (34) (33)(3,3)(3 1) (1 3) 01 tt baba ba AB R RP T ×× × − = (35) ()() 33 31 (1 3) 01 cd cd CD RP T ×× × = (36) bc (1 3) ΙP 01 BC T × = (37) ( ) ( ) 13 01 tt t bacdbabccdbaba AD RRR PPRP T × +− = (38) EFEB BA AF T TTT= ( 39) (3 1) (1 3) Ι 01 eb EB P T× × = (40) 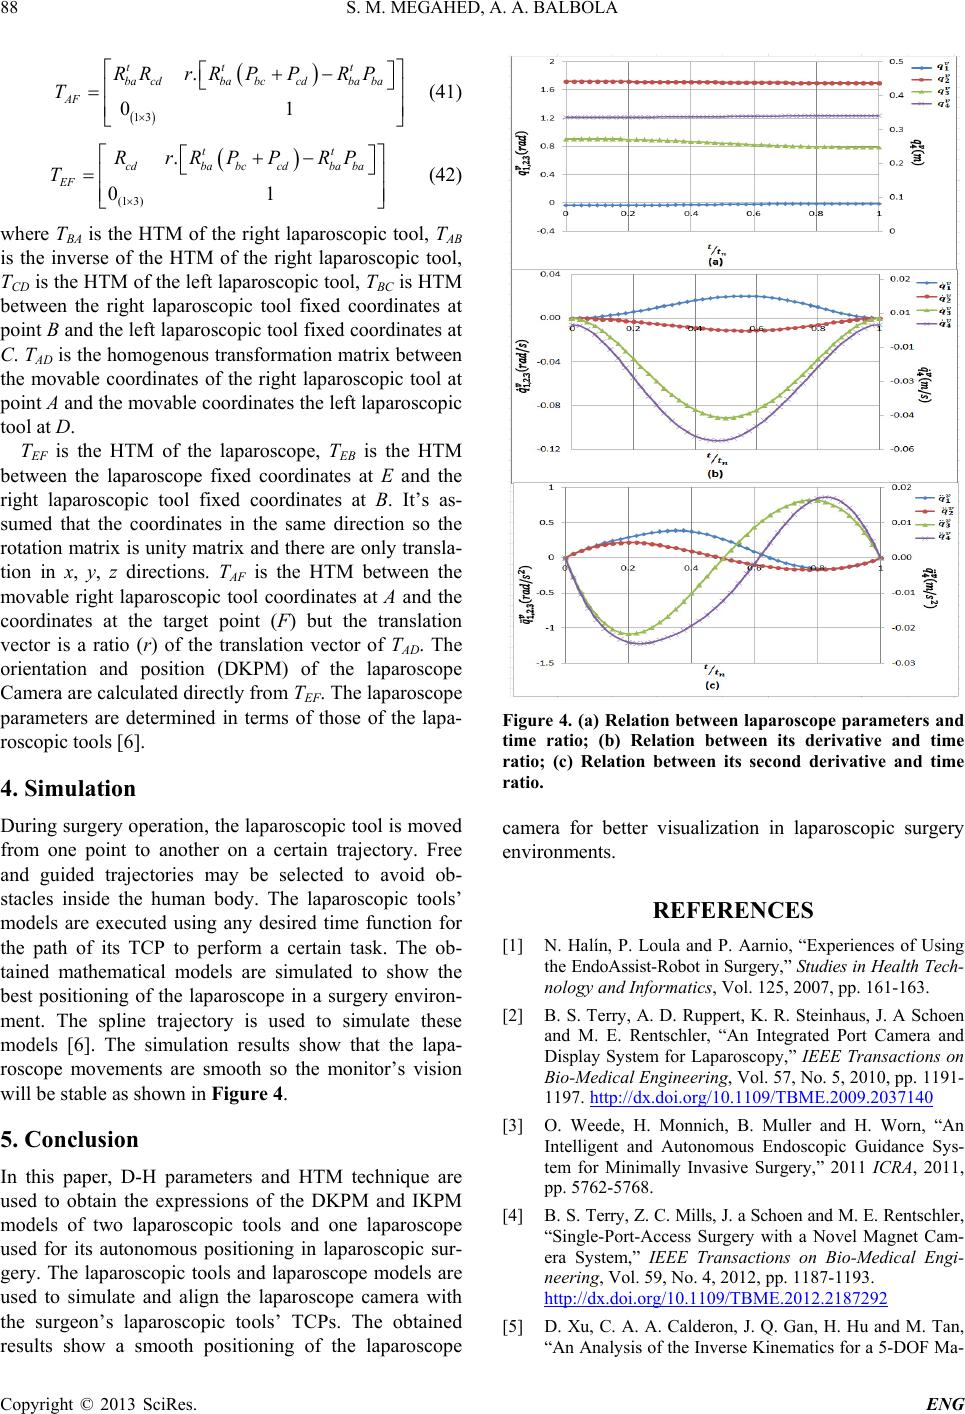 S. M. MEGAHED, A. A. BALBOLA Copyright © 2013 SciRes. ENG 88 ( ) ( ) 13 . 01 tt t bacdbabccdba ba AF RRrR PPRP T × +− = (41) ( ) (1 3) . 01 tt cdbabccdba ba EF RrR PPRP T × +− = (42) where TBA is the HTM of the right laparoscopic tool, TAB is the inverse of the HTM of the right laparoscopic tool, TCD is the HTM of the left laparoscopic tool, TBC is HTM between the right laparoscopic tool fixed coordinates at point B and the left laparoscopic tool f ixed coordinates at C. TAD is the homogenous transformation matrix between the movable coordinates of the right laparoscopic tool at point A and the movable coordinates the left laparoscopic tool at D. TEF is the HTM of the laparoscope, TEB is the HTM between the laparoscope fixed coordinates at E and the right laparoscopic tool fixed coordinates at B. It’s as- sumed that the coordinates in the same direction so the rotation matrix is unity matrix and there are only transla- tion in x, y, z directions. TAF is the HTM between the movable right laparoscopic tool coordinates at A and the coordinates at the target point (F) but the translation vector is a ratio (r) of the translation vector of TAD. The orientation and position (DKPM) of the laparoscope Camera are calculated directly from TEF. The laparoscope parameters are determined in terms of those of the lapa- roscopi c tools [6]. 4. Simulation During surgery operation, the laparoscopic tool is moved from one point to another on a certain trajectory. Free and guided trajectories may be selected to avoid ob- stacles inside the human body. The laparoscopic tools’ models are executed using any desired time function for the path of its TCP to perform a certain task. The ob- tained mathematical models are simulated to show the best positioning of the laparoscope in a surgery environ- ment. The spline trajectory is used to simulate these models [6]. The simulation results show that the lapa- roscope movements are smooth so the monitor’s vision will be stable as shown in Figure 4. 5. Conclusion In this paper, D-H parameters and HTM technique are used to obtain the expressions of the DKPM and IKPM models of two laparoscopic tools and one laparoscope used for its autonomous positioning in laparoscopic sur- gery. The laparoscopic tools and laparoscope models are used to simulate and align the laparoscope camera with the surgeon’s laparoscopic tools’ TCPs. The obtained results show a smooth positioning of the laparoscope Figure 4. (a) Relation between laparoscope parameters and time ratio; (b) Relation between its derivative and time ratio; (c) Relation between its second derivative and time ratio. camera for better visualization in laparoscopic surgery environments. REFERENCES [1] N. Halín, P. Loula and P. Aarnio, “Experiences of Using the EndoAssi st-Robot in Surgery,” Studies in Health Tech- nology and Informatics, Vol. 125, 2007, pp. 161-163. [2] B. S. Terry, A. D. Ruppert, K. R. Steinhaus, J. A Schoen and M. E. Rentschler, “An Integrated Port Camera and Display System for Laparoscopy,” IEEE Transactions on Bio-Medical Engineering, Vol. 57, No. 5, 2010, pp. 1191- 1197. http://dx.doi.org/10.1109/TBME.2009.2037140 [3] O. Weede, H. Monnich, B. Muller and H. Worn, “An Intelligent and Autonomous Endoscopic Guidance Sys- tem for Minimally Invasive Surgery,” 2011 ICRA, 2011, pp. 5762-5768. [4] B. S. Terry, Z. C. Mills, J. a Schoen and M. E. Rentschler, “Single-Port-Access Surgery with a Novel Magnet Cam- era System,” IEEE Transactions on Bio-Medical Engi- neering, Vol. 59, No. 4, 2012, pp. 1187-1193. http://dx.doi.org/10.1109/TBME.2012.2187292 [5] D. Xu, C. A. A. Calderon, J. Q. Gan, H. Hu and M. Tan, “An Analysis of the Inverse Kinematics for a 5-DOF Ma- 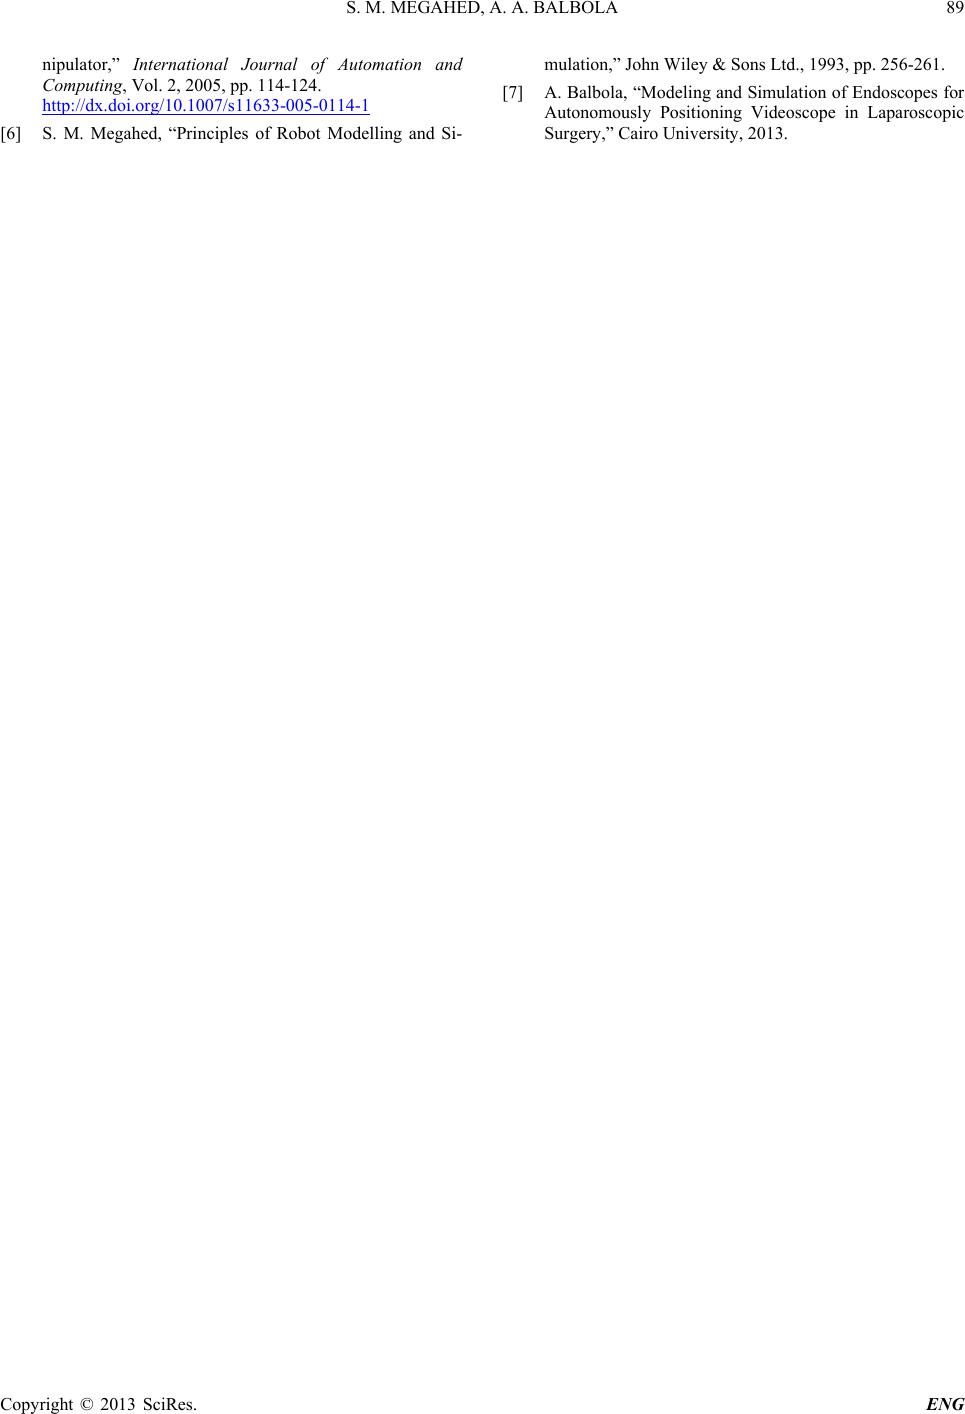 S. M. MEGAHED, A. A. BALBOLA Copyright © 2013 SciRes. ENG 89 nipulator,” International Journal of Automation and Computing, Vol. 2, 2005, pp. 114-124. http://dx.doi.org/10.1007/s11633-005-0114-1 [6] S. M. Megahed, “Principles of Robot Modelling and Si- mulation,” John Wiley & Sons Ltd., 1993, pp. 256-261. [7] A. Balbola, “Modeling and Simulation of Endoscopes for Autonomously Positioning Videoscope in Laparoscopic Surgery,” Cairo University, 2013. |