

Paper Menu >>
Journal Menu >>
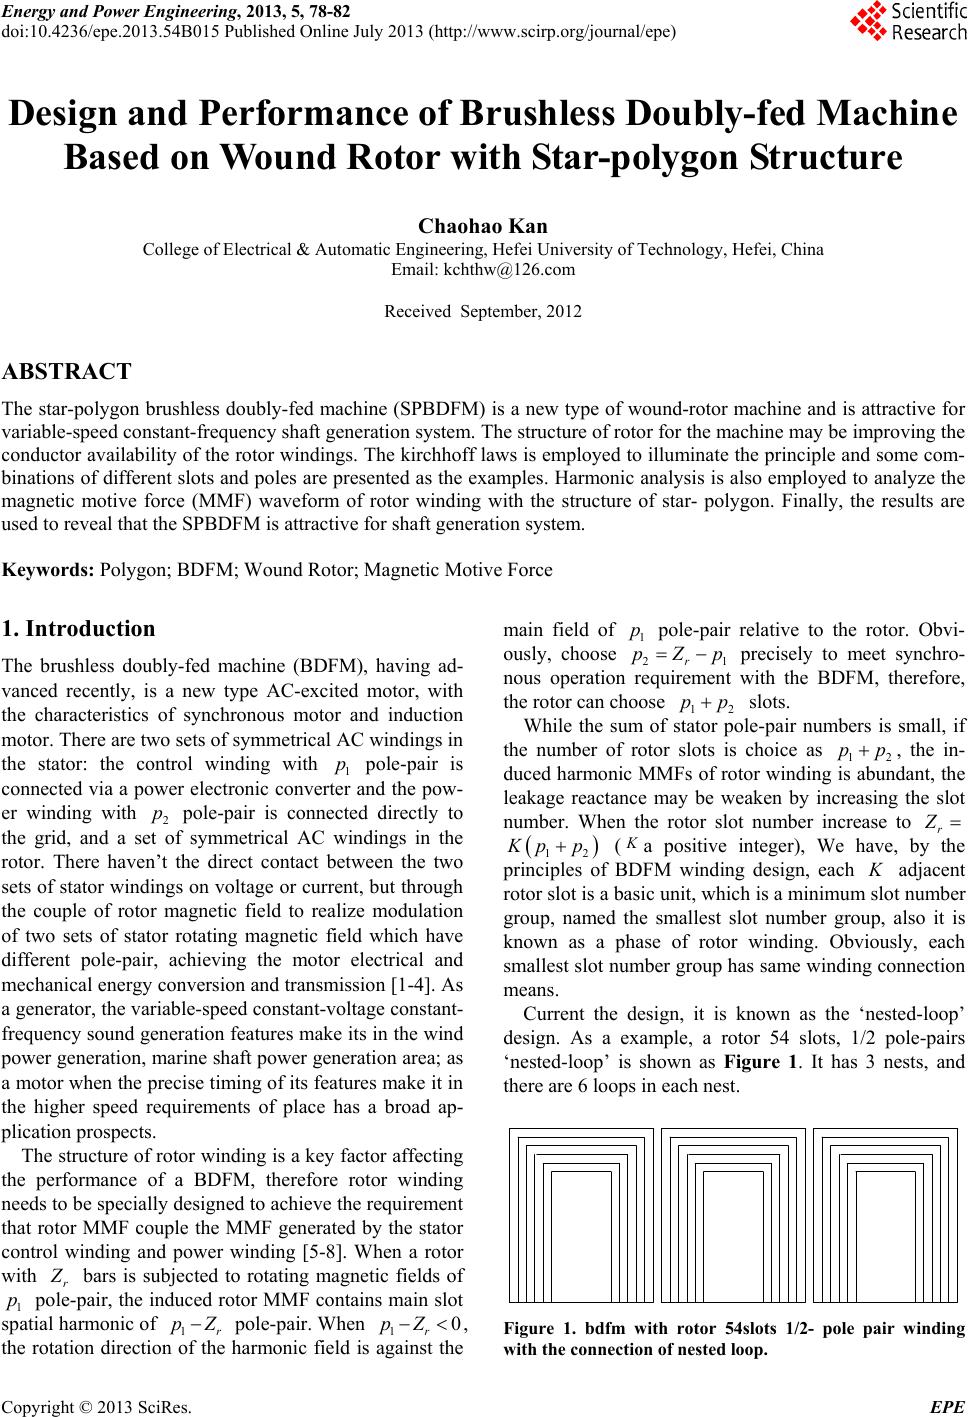 Energy and Power Engineering, 2013, 5, 78-82 doi:10.4236/epe.2013.54B015 Published Online July 2013 (http://www.scirp.org/journal/epe) Design and Performance of Brushless Doubly-fed Machine Based on Wound Rotor with Star-polygon Structure Chaohao Kan College of Electrical & Automatic Engineering, Hefei University of Technology, Hefei, China Email: [email protected] Received September, 2012 ABSTRACT The star-polygon bru shless doubly-fed machine (SPBDFM) is a new type of wound-rotor machine and is attractive fo r variable-speed constant-frequency shaft generation system. The structure of rotor for the machine may b e impro v ing the conductor availability of th e rotor windings. The kirchhoff laws is employed to illuminate the princip le and some com- binations of different slots and poles are presented as the examples. Harmonic analysis is also employed to analyze the magnetic motive force (MMF) waveform of rotor winding with the structure of star- polygon. Finally, the results are used to reveal that the SPBDFM is attractive for shaft generation system. Keywords: Polygon; BDFM; Wound Rotor; Magnetic Motive Force 1. Introduction The brushless doubly-fed machine (BDFM), having ad- vanced recently, is a new type AC-excited motor, with the characteristics of synchronous motor and induction motor. There are two sets of symmetrical AC windings in the stator: the control winding with 1 pole-pair is connected via a power electronic converter and the pow- er winding with 2 pole-pair is connected directly to the grid, and a set of symmetrical AC windings in the rotor. There haven’t the direct contact between the two sets of stator wind ings on voltage or cur rent, but through the couple of rotor magnetic field to realize modulation of two sets of stator rotating magnetic field which have different pole-pair, achieving the motor electrical and mechanical energy conversion and transmission [1-4]. A s a generator, the variable-speed constant-voltage constant- frequency sound generation features make its in the wind power generation, marine shaft power generation area; as a motor when the precise timing of its features make it in the higher speed requirements of place has a broad ap- plicatio n p rospect s. p p The structure of rotor winding is a k ey factor affecting the performance of a BDFM, therefore rotor winding needs to be specially desig ned to achiev e the requirement that rotor MMF couple the MMF generated by the stator control winding and power winding [5-8]. When a rotor with r Z bars is subjected to rotating magnetic fields of 1 pole-pair, the indu ced rotor MMF contains main slot spatial harmonic of 1r pole-pair. When 1 ppZ0 r pZ , the rotation direction of the harmonic field is against the main field of pole-pair relative to the rotor. Obvi- ously, choose 21r 1 p pZp p precisely to meet synchro- nous operation requirement with the BDFM, therefore, the rotor can choose 12 p slots. While the sum of stator pole-pair numbers is small, if the number of rotor slots is choice as 12 , the in- duced harmonic MMFs of rotor winding is abundant, the leakage reactance may be weaken by increasing the slot number. When the rotor slot number increase to r pp Z 12 K pp ( K a positive integer), We have, by the principles of BDFM winding design, each K adjacent rotor slot is a basic unit, which is a minimum slot number group, named the smallest slot number group, also it is known as a phase of rotor winding. Obviously, each smallest slot number group has same winding connection means. Current the design, it is known as the ‘nested-loop’ design. As a example, a rotor 54 slots, 1/2 pole-pairs ‘nested-loop’ is shown as Figure 1. It has 3 nests, and there are 6 loops in each nest. Figure 1. bdfm with rotor 54slots 1/2- pole pair winding with the connection of nested loop. Copyright © 2013 SciRes. EPE 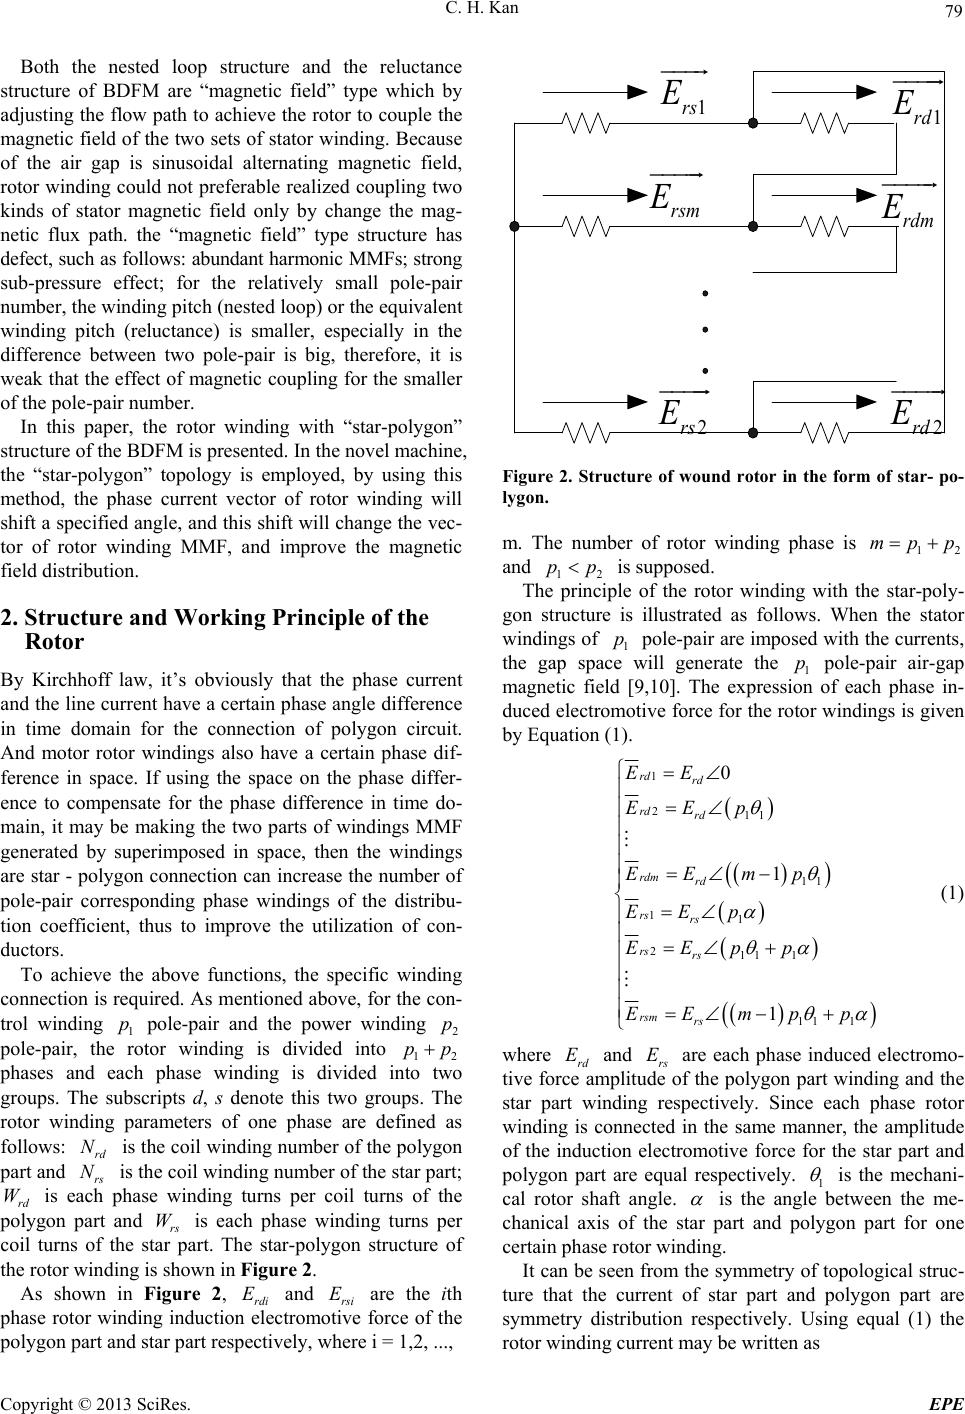 C. H. Kan 79 Both the nested loop structure and the reluctance structure of BDFM are “magnetic field” type which by adjusting the flow path to achieve the rotor to couple the magnetic field of the two sets of stator winding. Because of the air gap is sinusoidal alternating magnetic field, rotor winding could not preferable realized coupling two kinds of stator magnetic field only by change the mag- netic flux path. the “magnetic field” type structure has defect, such as follows: abundant harmonic MMFs; strong sub-pressure effect; for the relatively small pole-pair number, the winding pitch (nested loop) or the equivalent winding pitch (reluctance) is smaller, especially in the difference between two pole-pair is big, therefore, it is weak that the effect of magnetic coupling for the smaller of the pole - p a ir number. In this paper, the rotor winding with “star-polygon” structure of the BDFM is presented. In the novel machine, the “star-polygon” topology is employed, by using this method, the phase current vector of rotor winding will shift a specified angle, and this shift will change the vec- tor of rotor winding MMF, and improve the magnetic field distribution. 2. Structure and Working Principle of the Rotor By Kirchhoff law, it’s obviously that the phase current and the line current have a certain phase angle difference in time domain for the connection of polygon circuit. And motor rotor windings also have a certain phase dif- ference in space. If using the space on the phase differ- ence to compensate for the phase difference in time do- main, it may be making the two parts of windings MMF generated by superimposed in space, then the windings are star - polygon connection can increase the number of pole-pair corresponding phase windings of the distribu- tion coefficient, thus to improve the utilization of con- ductors. To achieve the above functions, the specific winding connection is requ ired. As mentioned above, for the con- trol winding 1 pole-pair and the power winding pole-pair, the rotor winding is divided into 12 p2 p pp phases and each phase winding is divided into two groups. The subscripts d, s denote this two groups. The rotor winding parameters of one phase are defined as follows: is the coil win ding number of the polygon part and rs is the coil winding number of the star part; rd is each phase winding turns per coil turns of the polygon part and rs is each phase winding turns per coil turns of the star part. The star-polygon structure of the rotor winding is shown in Figure 2. rd N N WW As shown in Figure 2, rdi and rsi are the ith phase rotor winding induction electromotive force of the polygon part an d star part respectively, where i = 1,2, ..., E E 1rs E rsm E 2rs E 1rd E rdm E 2rd E Figure 2. Structure of wound rotor in the form of star- po- lygon. m. The number of rotor winding phase is 12 mp p and 12 pp is supposed. The principle of the rotor winding with the star-poly- gon structure is illustrated as follows. When the stator windings of 1 pole-pair are imposed with the currents, the gap space will generate the 1 pole-pair air-gap magnetic field [9,10]. The expression of each phase in- duced electromotive force for the rotor windings is given by Equation (1). pp 1 211 11 11 211 1 11 1 0 1 1 rd rd rd rd rdm rd rs rs rs rs rsm rs EE EEp EEmp EEp EEpp EEmpp (1) where rd and rs are each phase induced electromo- tive force amplitude of the polygon part winding and the star part winding respectively. Since each phase rotor winding is connected in the same manner, the amplitude of the induction electromotive force for the star part and polygon part are equal respectively. 1 E E is the mechani- cal rotor shaft angle. is the angle between the me- chanical axis of the star part and polygon part for one certain phase rotor winding. It can be seen from the symmetry of topological struc- ture that the current of star part and polygon part are symmetry distribution respectively. Using equal (1) the rotor winding current may be written as Copyright © 2013 SciRes. EPE 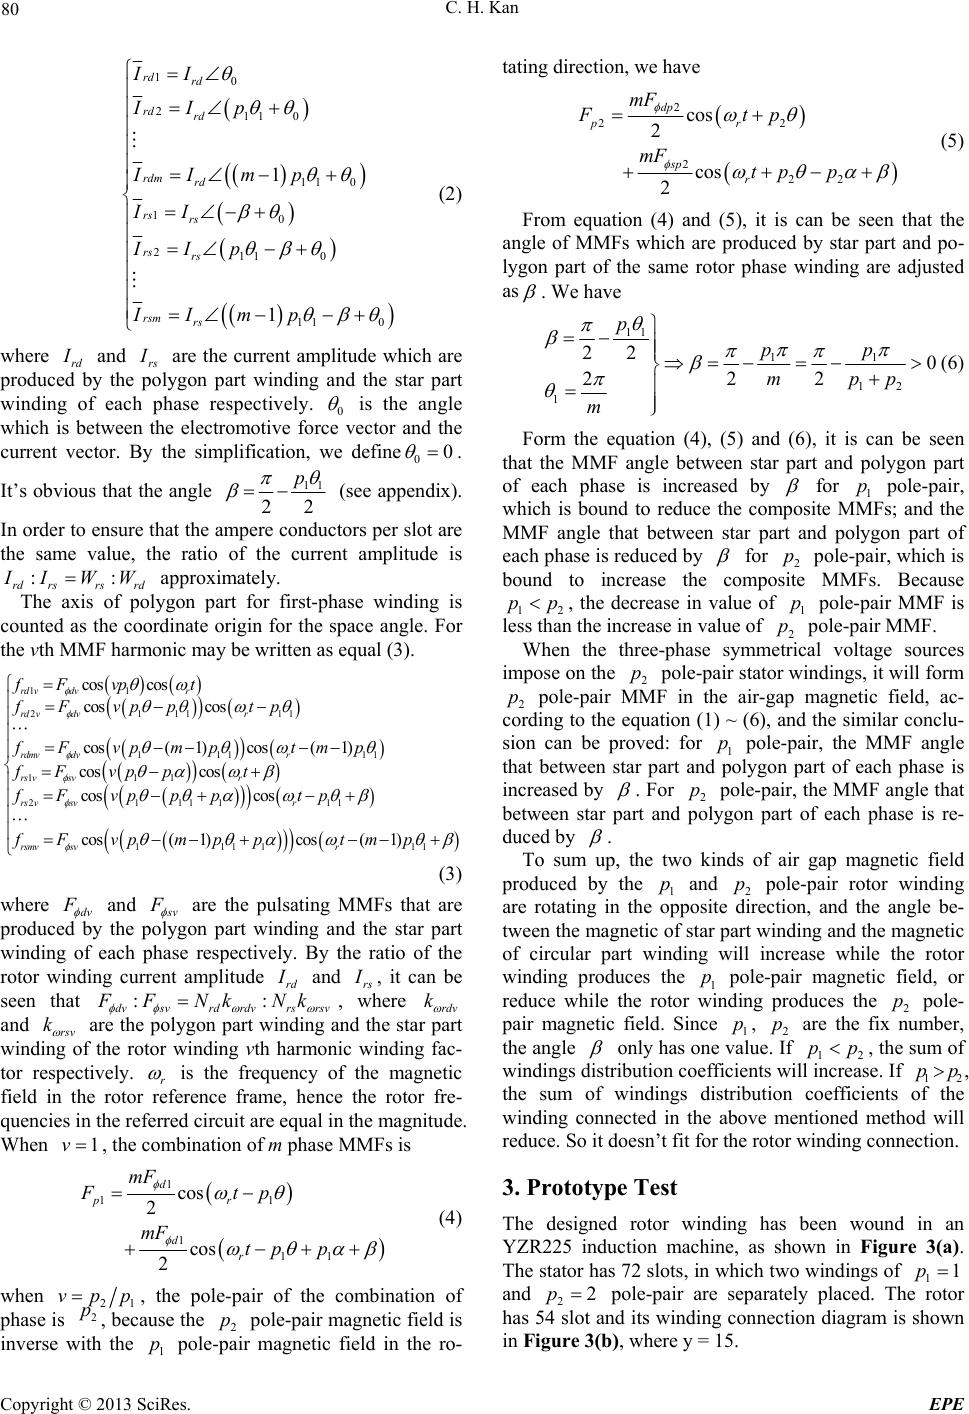 C. H. Kan 80 10 211 0 11 0 10 211 0 11 0 1 1 rd rd rd rd rdm rd rs rs rs rs rsm rs II IIp IImp II IIp IImp (2) where rd I and rs I are the current amplitude which are produced by the polygon part winding and the star part winding of each phase respectively. 0 is the angle which is between the electromotive force vector and the current vector. By the simplification, we define00 . It’s obvious that the angle 11 22 p (see appendix). In order to ensure that the ampere conductors per slot are the same value, the ratio of the current amplitude is :: rd rsrsrd I IWW approximately. The axis of polygon part for first-phase winding is counted as the coordinate origin for the space angle. For the vth MMF harmonic may be written as equal (3). 11 21 1111 111 11 111 21111 11 1111 cos cos cos cos cos( 1)cos( 1) cos cos cos cos cos( 1) rd vdvr rd vdvr rdmv dvr rs vsvr rs vsvr rsmv sv fF vpt fF vpptp fF vpmptmp fF vppt fF vppptp fF vpmpp 11 cos( 1) rtm p (3) where dv F and s v F are the pulsating MMFs that are produced by the polygon part winding and the star part winding of each phase respectively. By the ratio of the rotor winding current amplitude rd I and rs I , it can be seen that rdrdvrs rsv :: dv sv F FNkkN , where rdv and rsv are the polygon part winding and the star part winding of the rotor winding vth harmonic winding fac- tor respectively. r k k is the frequency of the magnetic field in the rotor reference frame, hence the rotor fre- quencies in the referred circuit are equal in the magnitude. When , the combination of m phase MMFs is 1v 1 11 111 cos 2 cos 2 d pr dr mF Ftp mF tp p (4) when 21 vpp, the pole-pair of the combination of phase is , because the 2 pole-pair magnetic field is inverse with the pole-pair magnetic field in the ro- tating direction, we have 2 pp 1 p 2 22 222 cos 2 cos 2 dp pr sp r mF Ftp mF tp p (5) From equation (4) and (5), it is can be seen that the angle of MMFs which are produced by star part and po- lygon part of the same rotor phase winding are adjusted as . We have 11 11 12 1 22 0 222 ppp mpp m (6) Form the equation (4), (5) and (6), it is can be seen that the MMF angle between star part and polygon part of each phase is increased by for 1 pole-pair, which is bound to reduce the composite MMFs; and the MMF angle that between star part and polygon part of each phase is reduced by p for 2 pole-pair, which is bound to increase the composite MMFs. Because 12 p pp , the decrease in value of 1 pole-pair MMF is less than the increase in value of pole-pair MMF. p p2 When the three-phase symmetrical voltage sources impose on the 2 pole-pair stator windings, it will form 2 pole-pair MMF in the air-gap magnetic field, ac- cording to the equation (1) ~ (6), and the similar conclu- sion can be proved: for 1 pole-pair, the MMF angle that between star part and polygon part of each phase is increased by p p p . For 2 pole-pair, the MMF angle that between star part and polygon part of each phase is re- duced by p . To sum up, the two kinds of air gap magnetic field produced by the 1 and 2 pole-pair rotor winding are rotating in the opposite direction, and the angle be- tween the magnetic of star part winding and the magnetic of circular part winding will increase while the rotor winding produces the 1 pole-pair magnetic field, or reduce while the rotor winding produces the 2 pole- pair magnetic field. Since 1, 2 are the fix number, the angle p p p pp p only has one value. If 12 , the sum of windings distribution coefficients will increase. If 12 , the sum of windings distribution coefficients of the winding connected in the above mentioned method will reduce. So it doesn’t fit for the rotor winding connection. pppp 3. Prototype Test The designed rotor winding has been wound in an YZR225 induction machine, as shown in Figure 3(a). The stator has 72 slots, in which two windings of 11p and 22p pole-pair are separately placed. The rotor has 54 slot and its winding connection diagram is shown in Figure 3(b), where y = 15. Copyright © 2013 SciRes. EPE 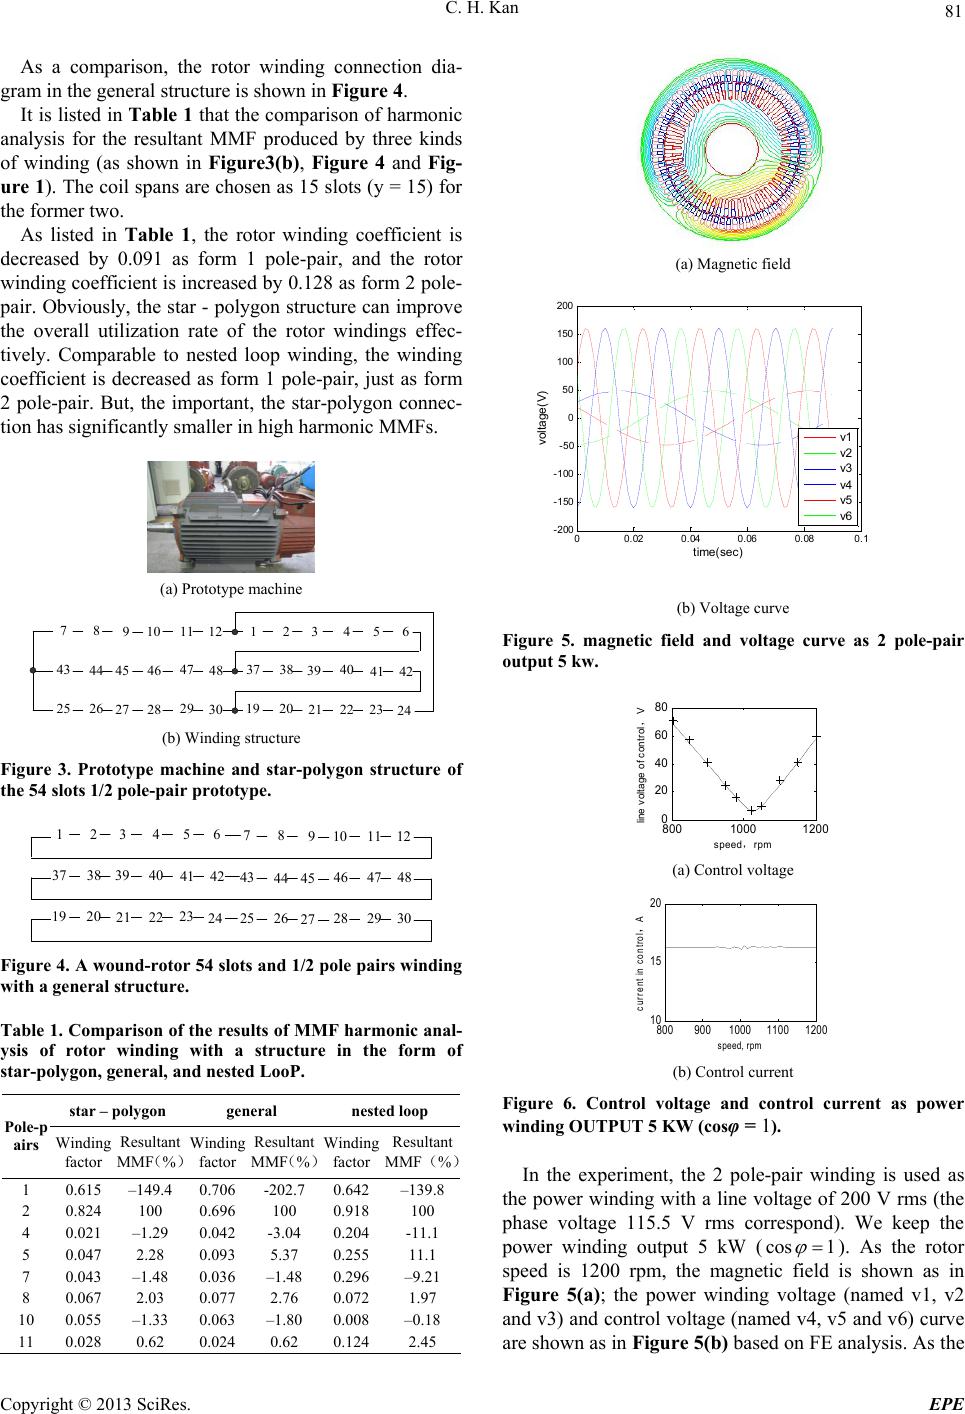 C. H. Kan 81 As a comparison, the rotor winding connection dia- gram in the general structure is shown in Figure 4. It is listed in Table 1 that the comparison of harmonic analysis for the resultant MMF produced by three kinds of winding (as shown in Figure3(b), Figure 4 and Fig- ure 1). The coil s pans are cho sen as 15 slo ts (y = 15) for the former two. As listed in Table 1, the rotor winding coefficient is decreased by 0.091 as form 1 pole-pair, and the rotor winding coefficient is increased by 0.128 as form 2 pole- pair. Obviously, the star - polygon structure can improve the overall utilization rate of the rotor windings effec- tively. Comparable to nested loop winding, the winding coefficient is decreased as form 1 pole-pair, just as form 2 pole-pair. But, the important, the star-polygon connec- tion has significantly smaller in high harmonic MMFs. (a) Prototype machine 3 42 15 39 40 3837 41 21 22 2019 23 10 11 8 7 12 46 47 44 43 48 28 29 2625 30 6 42 9 45 27 24 (b) Winding structure Figure 3. Prototype machine and star-polygon structure of the 54 slots 1/2 pole-pair prototype. 3 42 1 5 39 40 38 37 41 21 22 20 19 23 6 42 24 10 11 8 7 12 46 47 44 43 48 28 29262530 9 45 27 Figure 4. A wound-rotor 54 slots and 1/2 pole pairs winding with a general structure. Table 1. Comparison of the results of MMF harmonic anal- ysis of rotor winding with a structure in the form of star-polygon, general, and nested LooP. star – polygon general nested loop Pole-p airs Winding factor Resultant MMF(%) Winding factor Resultant MMF(%) Winding factor Resultant MMF(%) 1 0.615 –149.4 0.706 -202.7 0.642 –139.8 2 0.824 100 0.696 100 0.918 100 4 0.021 –1.29 0.042 -3.04 0.204 -11.1 5 0.047 2.28 0.093 5.37 0.255 11.1 7 0.043 –1.48 0.036 –1.48 0.296 –9.21 8 0.067 2.03 0.077 2.76 0.072 1.97 10 0.055 –1.33 0.063 –1.80 0.008 –0.18 11 0.028 0.62 0.024 0.62 0.124 2.45 (a) Magnetic field 00.02 0.040.06 0.080.1 -200 -150 -100 -50 0 50 100 150 200 time(sec) voltage(V) v1 v2 v3 v4 v5 v6 (b) Voltage curve Figure 5. magnetic field and voltage curve as 2 pole-pair output 5 kw. 800 1000 1200 0 20 40 60 80 line voltage of control , V speed , rpm (a) Control voltage 80090010001100 1200 10 15 20 current in control , A speed, rpm (b) Control current Figure 6. Control voltage and control current as power winding OUTPUT 5 KW (cosφ = 1). In the experiment, the 2 pole-pair winding is used as the power winding with a line voltage of 200 V rms (the phase voltage 115.5 V rms correspond). We keep the power winding output 5 kW (cos 1 ). As the rotor speed is 1200 rpm, the magnetic field is shown as in Figure 5(a); the power winding voltage (named v1, v2 and v3) and contro l voltage (named v4, v5 and v6) curv e are shown as in Figure 5(b) based on FE analysis. As the Copyright © 2013 SciRes. EPE 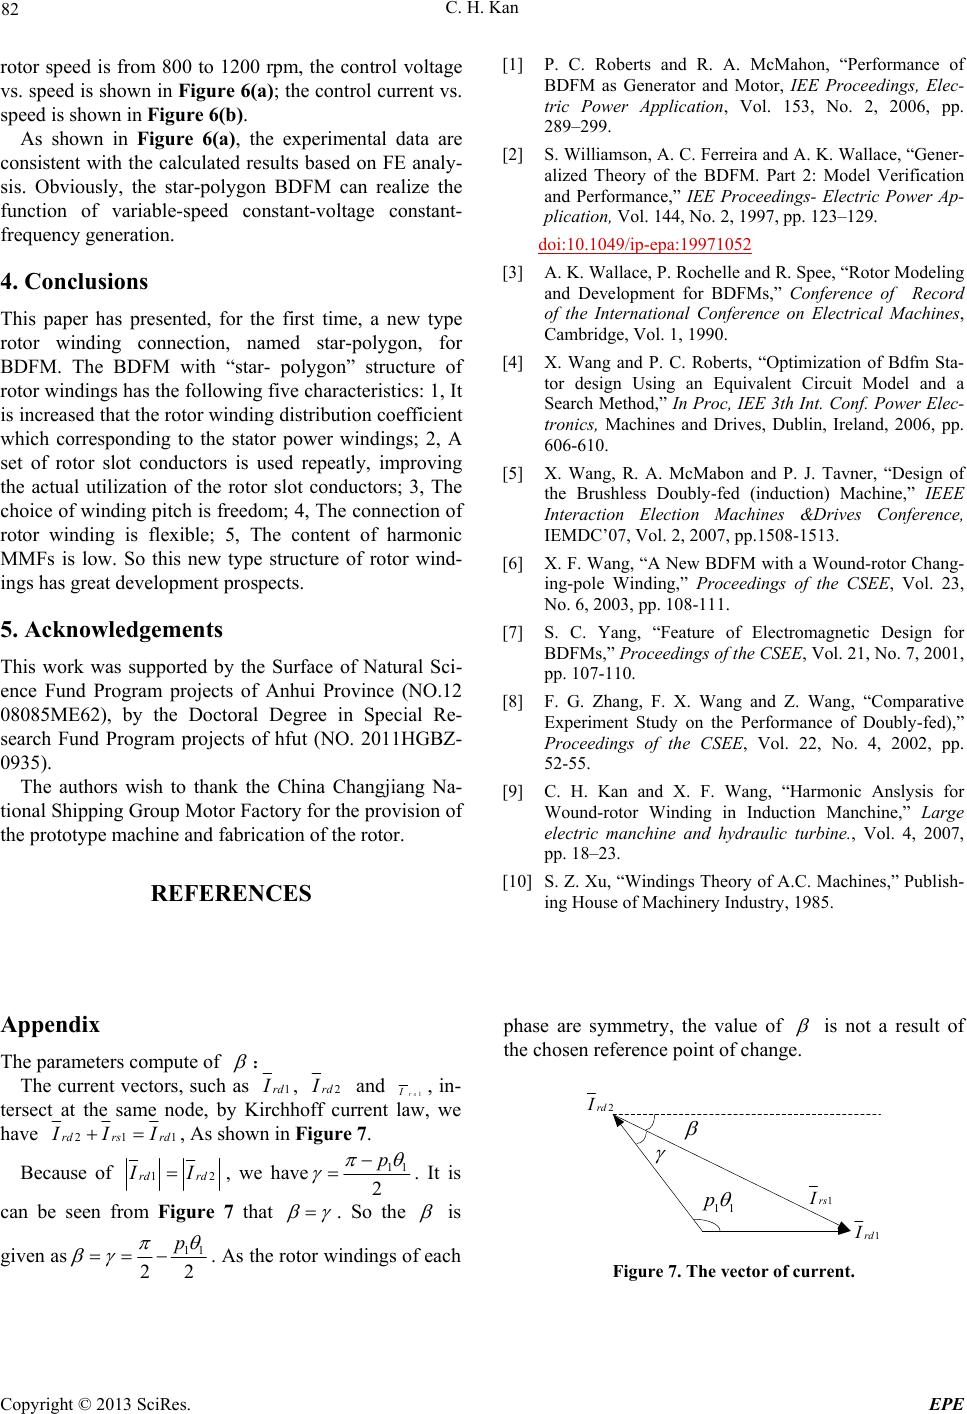 C. H. Kan Copyright © 2013 SciRes. EPE 82 [1] P. C. Roberts and R. A. McMahon, “Performance of BDFM as Generator and Motor, IEE Proceedings, Elec- tric Power Application, Vol. 153, No. 2, 2006, pp. 289–299. rotor speed is from 800 to 1200 rpm, the control voltage vs. speed is shown in Figure 6(a); the control current vs. speed is shown in F igure 6( b ). As shown in Figure 6(a), the experimental data are consistent with the calculated results based on FE analy- sis. Obviously, the star-polygon BDFM can realize the function of variable-speed constant-voltage constant- frequency generation. [2] S. Williamson, A. C. Ferreira and A. K. Wallace, “Gener- alized Theory of the BDFM. Part 2: Model Verification and Performance,” IEE Proceedings- Electric Power Ap- plication, Vol. 144, No. 2, 1997, pp. 123–129. doi:10.1049/ip-epa:19971052 [3] A. K. Wallace, P. Rochelle and R. Spee, “Rotor Modeling and Development for BDFMs,” Conference of Record of the International Conference on Electrical Machines, Cambridge, Vol. 1, 1990. 4. Conclusions This paper has presented, for the first time, a new type rotor winding connection, named star-polygon, for BDFM. The BDFM with “star- polygon” structure of rotor windings has the following five characteristics: 1, It is increased that the rotor winding distribution coefficient which corresponding to the stator power windings; 2, A set of rotor slot conductors is used repeatly, improving the actual utilization of the rotor slot conductors; 3, The choice of winding pitch is freedom; 4, The connection of rotor winding is flexible; 5, The content of harmonic MMFs is low. So this new type structure of rotor wind- ings has great development prospects. [4] X. Wang and P. C. Roberts, “Optimization of Bdfm Sta- tor design Using an Equivalent Circuit Model and a Search Method,” In Proc, IEE 3th Int. Conf. Power Elec- tronics, Machines and Drives, Dublin, Ireland, 2006, pp. 606-610. [5] X. Wang, R. A. McMabon and P. J. Tavner, “Design of the Brushless Doubly-fed (induction) Machine,” IEEE Interaction Election Machines &Drives Conference, IEMDC’07, Vol. 2, 2007, pp.1508-1513. [6] X. F. Wang, “A New BDFM with a Wound-rotor Chang- ing-pole Winding,” Proceedings of the CSEE, Vol. 23, No. 6, 2003, pp. 108-111. 5. Acknowledgements [7] S. C. Yang, “Feature of Electromagnetic Design for BDFMs,” Proceedings of the CSEE, Vol. 21, No. 7, 2001, pp. 107-110. This work was supported by the Surface of Natural Sci- ence Fund Program projects of Anhui Province (NO.12 08085ME62), by the Doctoral Degree in Special Re- search Fund Program projects of hfut (NO. 2011HGBZ- 0935). [8] F. G. Zhang, F. X. Wang and Z. Wang, “Comparative Experiment Study on the Performance of Doubly-fed),” Proceedings of the CSEE, Vol. 22, No. 4, 2002, pp. 52-55. The authors wish to thank the China Changjiang Na- tional Shipping Group Motor Factory for the provision of the prototype machine and fabrication of the rotor. [9] C. H. Kan and X. F. Wang, “Harmonic Anslysis for Wound-rotor Winding in Induction Manchine,” Large electric manchine and hydraulic turbine., Vol. 4, 2007, pp. 18–23. [10] S. Z. Xu, “Windings Theory of A.C. Machines,” Publish- ing House of Machinery Industry, 1985. REFERENCES Appendix phase are symmetry, the value of is not a result of the chosen reference point of change. The parameters compute of : The current vectors, such as 1rd I , 2rd I and 1rs I , in- tersect at the same node, by Kirchhoff current law, we have 21rdrs rd 1rd I 2rd I 1rs I 11 p 1 I II, As shown in Figure 7. Because of 1rdrd 2 I I, we have11 2 p . It is can be seen from Figure 7 that . So the is given as11 22 p . As the rotor windings of each Figure 7. The vector of current. |