

Paper Menu >>
Journal Menu >>
 Engineering, 2013, 5, 43-50 http://dx.doi.org/10.4236/eng.2013.59B008 Published Online September 2013 (http://www.scirp.org/journal/eng) Copyright © 2013 SciRes. ENG PI-MPC Frequency Con trol of Power System in th e Presence of DFIG Win d Turbines Michael Z. Bernard 1, T. H. Mohamed2, Raheel Ali1, Yasunori Mitani1, Yaser Soliman Qudaih1 1Department of Electrical Engineering and Electronics, Kyushu Institute of Technology, Fukuoka, Japan 2Faculty of Energy Eng., Aswan University, Aswan, Egypt Email: mzbe rna [email protected], [email protected], raheel.ali@hotmail.co.jp, Received July 2013 Abstract For the recent expansion of renewable energy applications, Wind Energy System (WES) is receiving much interest all over the world. However, area load change and abnormal conditions lead to mismatches in frequency and scheduled power interchanges between areas. These mismatches have to be corrected by the LFC system. This paper, therefore, proposes a new robust frequency control technique involving the combination of conventional Proportional-Integral (PI) and Model Predictive Control (MPC) controllers in the presence of wind turbines (WT) . The PI-MPC technique has been designed such that the effect of the uncertainty due to governor and turbine parameters variation and load distur- bance is reduced. A frequency response dynamic model of a single-area power system with an aggregated generator unit is introduced, and physical constraints of the governors and turbines are considered. The proposed technique is tested on the single-area power system, for enhancement of the network frequency quality. The validity of the proposed method is evaluated by computer simulation analyses using Matlab Simulink. The results show that, with the proposed PI-MPC combination technique, the overall closed loop system performance demonstrated robustness regardless of the presence of uncertainties due to variations of the parameters of governors and turbines, and loads disturbances. A per- formance comparison between the proposed control scheme, the classical PI control scheme and the MPC is carried out confirming the superiority of the proposed technique in presence of doubly fed induction generator (DFIG) WT. Keywords: Doubly Fed Induct ion Generat o r; Power Syste m; Model Predictive Control); Proportional Integral Controller; DFIG Wind Turbi ne; Wind Energ y System (WES) 1. Introduction Two balances corresponding to two equilibrium points namely frequency and voltage must be maintained be- tween generation and utilization in an electric power system. This enables generation and distribution of qual- ity electrical power to factories and homes. Breaking or resetting either of the two balances to a new level will constitute floating of the equilibrium points. When either of the two balances is broken and reset at a new level, the equilibrium points will float. A good-quality electric power system requires both the frequency and voltage to remain at standard values during operation. Thus a control system is important to mitigate the ef- fects of the random load changes and keep the frequency and voltage at the standard values. Although active and reactive power affects the frequency and voltage respec- tively, the frequency is highly dependent on the active power while the voltage is highly dependent on the reac- tive power. Thus the control issue in power systems can be decoupled into two independent problems. One is about the active power and frequency control while the other is about the reactive power and voltage control. The active power and frequency control is referred to as load frequency control (LFC) [1] which is the major concern of this paper. LFC objectives, which determine the LF C synthesis as a multi-objective optimization problem [2,3] are con- cerned with, frequency regulation and tracking the load demands, maintaining the tie-line power interchanges to specified values in the presence of modeling uncertain- ties, system nonlinearities and area load disturbances. Hence, Frequency control or Load frequency control is an important function of power system operation where the main objective is to regulate the output power of each generator at prescribed levels while keeping the fre- quency fl uc tuations w i thin pre-specified limits [4]. On the other hand, energy problems and environmen- tal issues have led to, with recent expansion of renewable energies, power systems. WES is the fastest growing and mostly utilized of all the renewable energies and its 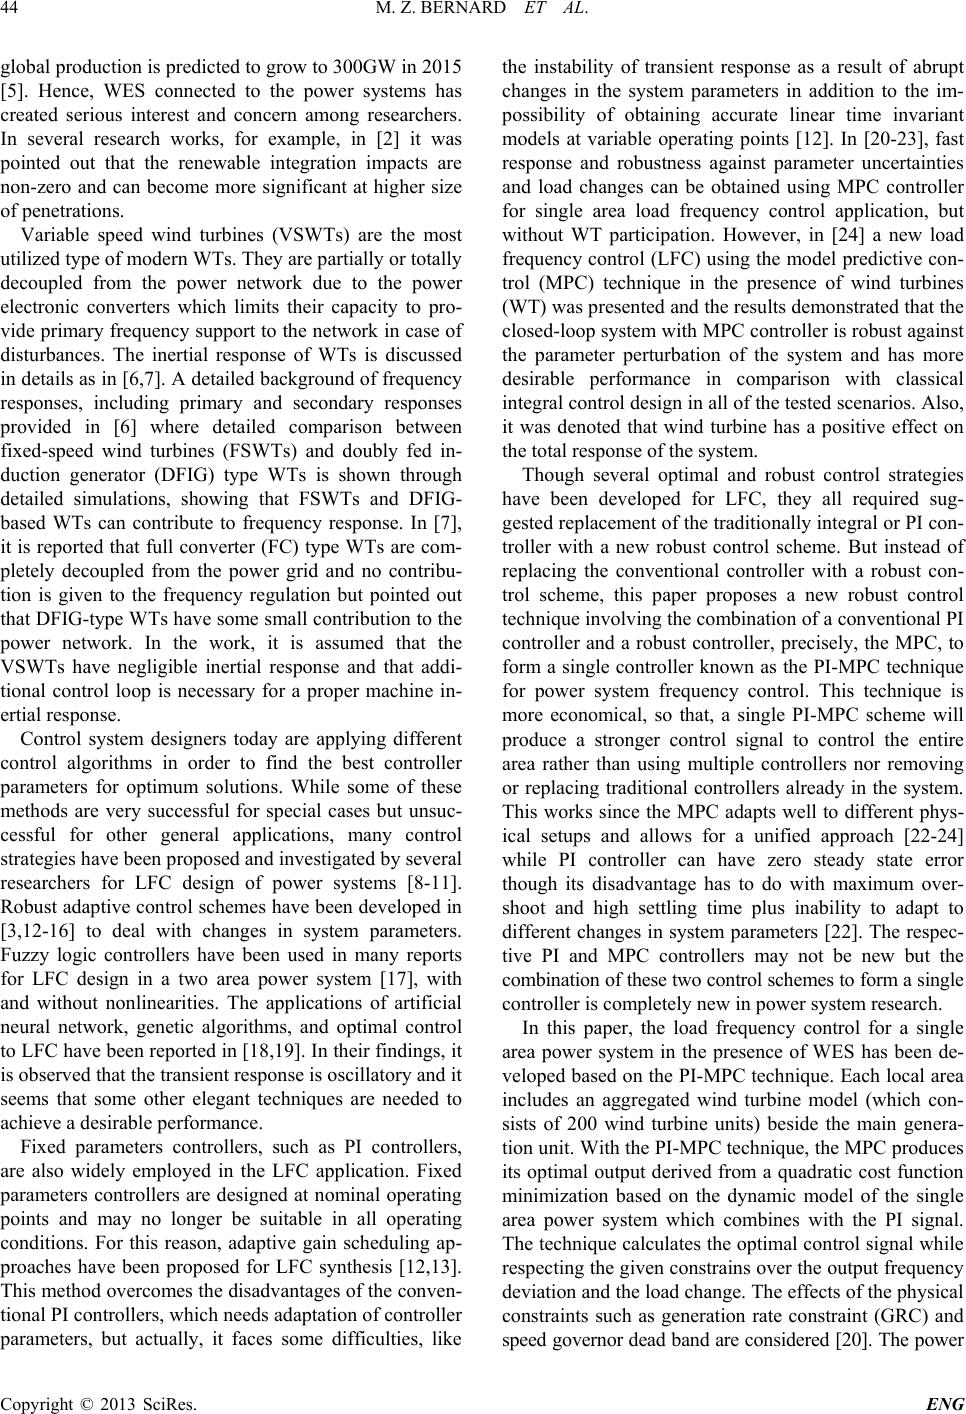 M. Z. BERNARD ET AL. Copyright © 2013 SciRes. ENG 44 global produc tion is pr edicte d to gr ow to 300GW in 2015 [5]. Hence, WES connected to the power systems has created serious interest and concern among researchers. In several research works, for example, in [2] it was pointed out that the renewable integration impacts are non-zero and can become more significant at higher size of penetrations. Variable speed wind turbines (VSWTs) are the most utilized type of modern WTs. They are partially or totally decoupled from the power network due to the power electronic converters which limits their capacity to pro- vide primary frequ ency support to the network in case of disturbances. The inertial response of WTs is discussed in details as in [ 6,7]. A detailed background of frequency responses, including primary and secondary responses provided in [6] where detailed comparison between fixed-speed wind turbines (FSWTs) and doubly fed in- duction generator (DFIG) type WTs is shown through detailed simulations, showing that FSWTs and DFIG- based WTs can contribute to frequency response. In [7], it is reported that full converter (FC) type WTs are com- pletely decoupled from the power grid and no contribu- tion is given to the frequency regulation but pointed out that DFIG-type WTs have some small contribution to the power network. In the work, it is assumed that the VSWTs have negligible inertial response and that addi- tional control loop is necessary for a proper machine in- ertial response. Control system designers today are applying different control algorithms in order to find the best controller parameters for optimum solutions. While some of these methods are very successful for special cases but unsuc- cessful for other general applications, many control strategies have been proposed and investigated by several researchers for LFC design of power systems [8-11]. Robust adaptive control schemes have been developed in [3,12-16] to deal with changes in system parameters. Fuzzy logic controllers have been used in many reports for LFC design in a two area power system [17], with and without nonlinearities. The applications of artificial neural network, genetic algorithms, and optimal control to LFC have been reported in [18,19]. In their findings, it is observed that the transient response is oscillatory and it seems that some other elegant techniques are needed to achieve a desirable performance. Fixed parameters controllers, such as PI controllers, are also widely employed in the LFC application. Fixed parameters controllers are designed at nominal operating points and may no longer be suitable in all operating conditions. For this reason, adaptive gain scheduling ap- proaches have been proposed for LFC synthesis [12,13]. This method overcomes the disadvantages of the conven- tional PI controllers, which needs adaptation of controller parameters, but actually, it faces some difficulties, like the instability of transient response as a result of abrupt changes in the system parameters in addition to the im- possibility of obtaining accurate linear time invariant models at variable operating points [12]. In [20-23], fast response and robustness against parameter uncertainties and load changes can be obtained using MPC controller for single area load frequency control application, but without WT participation. However, in [24] a new load frequency control (LFC) using the model predictive con- trol (MPC) technique in the presence of wind turbines (WT) was presented and the results demonstrated that the closed-loop system with MPC controller is robust against the parameter perturbation of the system and has more desirable performance in comparison with classical integral control design in all of the tested scenarios. Also, it was denoted that wind turbine has a positive effect on the total response of the system. Though several optimal and robust control strategies have been developed for LFC, they all required sug- gested replacement of the traditionally integral or PI con- troller with a new robust control scheme. But instead of replacing the conventional controller with a robust con- trol scheme, this paper proposes a new robust control technique involving the combination of a conventional PI controller and a robust controller, precisely, the MPC, to form a single controller known as the PI-MPC technique for power system frequency control. This technique is more economical, so that, a single PI-MPC scheme will produce a stronger control signal to control the entire area rather than using multiple controllers nor removing or replacing traditional controllers already in the system. This works since the MPC adapts well to different phys- ical setups and allows for a unified approach [22-24] while PI controller can have zero steady state error though its disadvantage has to do with maximum over- shoot and high settling time plus inability to adapt to different changes in system parameters [22]. The respec- tive PI and MPC controllers may not be new but the combination of these two control schemes to form a single controller is completely new in power system research. In this paper, the load frequency control for a single area power system in the presence of WES has been de- veloped based on the PI-MPC technique. Each local area includes an aggregated wind turbine model (which con- sists of 200 wind turbine units) beside the main genera- tion unit. With the PI-MPC technique, the MPC produces its optimal output derived from a quadratic cost function minimization based on the dynamic model of the single area power system which combines with the PI signal. The technique calculates the optimal control signal while respecting the given constrains over the output frequency deviation and the load change. The effects of the physical constraints such as generation rate constraint (GRC) and speed governor dead band are considered [20]. The power 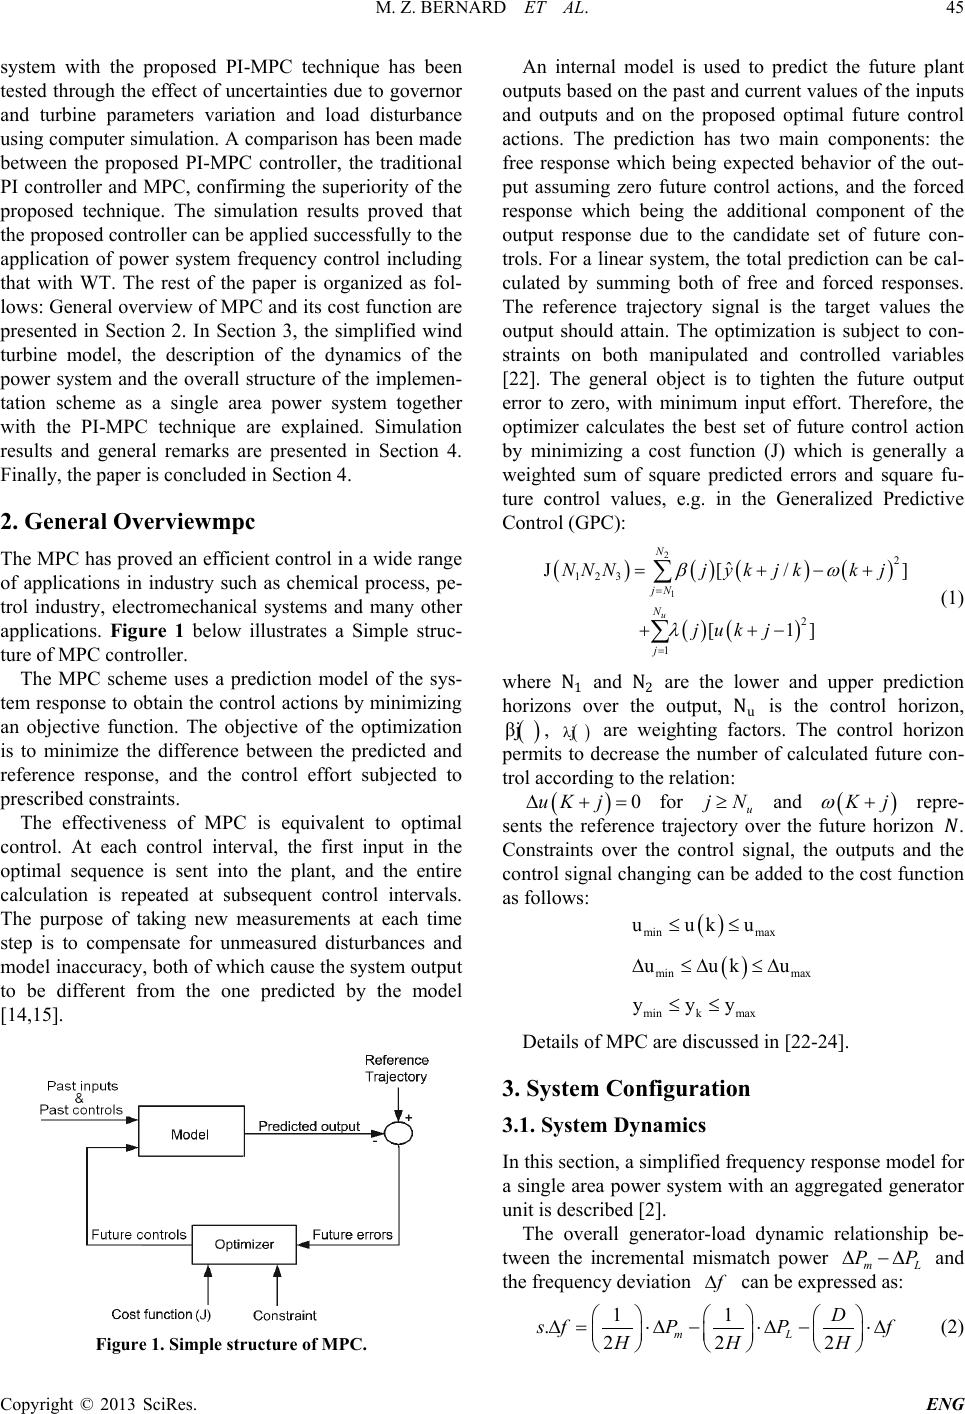 M. Z. BERNARD ET AL. Copyright © 2013 SciRes. ENG 45 system with the proposed PI-MPC technique has been tested through the effect of uncertainties due to go vernor and turbine parameters variation and load disturbance using computer simulation. A comparison has been made between the proposed PI-MPC controller, the traditional PI controller and MPC, confirming the superiority of the proposed technique. The simulation results proved that the proposed controller can be applied successfully to the application of power system frequency control including that with WT. The rest of the paper is organized as fol- lows: General overview of MPC and its cost function are presented in Section 2. In Section 3, the simplified wind turbine model, the description of the dynamics of the power system and the overall structure of the implemen- tation scheme as a single area power system together with the PI-MPC technique are explained. Simulation results and general remarks are presented in Section 4. Finally, the paper is concluded in Section 4. 2. General Overvi e wmpc The MPC has proved an efficient control in a wide range of applications in industry such as chemical process, pe- trol industry, electromechanical systems and many other applications. Figure 1 below illustrates a Simple struc- ture of MPC controller. The MPC scheme uses a prediction model of the sys- tem response to obtain the control actions by minimizing an objective function. The objective of the optimization is to minimize the difference between the predicted and reference response, and the control effort subjected to prescribed constraints. The effectiveness of MPC is equivalent to optimal control. At each control interval, the first input in the optimal sequence is sent into the plant, and the entire calculation is repeated at subsequent control intervals. The purpose of taking new measurements at each time step is to compensate for unmeasured disturbances and model inaccuracy, both of which cause the system output to be different from the one predicted by the model [14,15]. Figure 1. Simple structure of MP C. An internal model is used to predict the future plant outputs based on the past and current values of the inputs and outputs and on the proposed optimal future control actions. The prediction has two main components: the free response which being expected behavior of the out- put assuming zero future control actions, and the forced response which being the additional component of the output response due to the candidate set of future con- trols. For a linear system, the total prediction can be cal- culated by summing both of free and forced responses. The reference trajectory signal is the target values the output should attain. The optimization is subject to con- straints on both manipulated and controlled variables [22]. The general object is to tighten the future output error to zero, with minimum input effort. Therefore, the optimizer calculates the best set of future control action by minimizing a cost function (J) which is generally a weighted sum of square predicted errors and square fu- ture control values, e.g. in the Generalized Predictive Control (GPC): ( ) ( )()() ( )() 2 1 2 123 2 1 ˆ J[/ ] [ 1] u N jN N j NNNjykjk kj j ukj βω λ = = =+ −+ + +− ∑ ∑ (1) where N1 and N2 are the lower and upper prediction horizons over the output, Nu is the control horizon, ( ) βj , ( ) λj are weighting factors. The control horizon permits to decrease the number of calculated future con- trol according to the relation: ( ) 0uK j∆ += for u jN ≥ and ( ) Kj ω + repre- sents the reference trajectory over the future horizon . Constraints over the control signal, the outputs and the control signal changing can be added to the cost function as follows : ( ) min max uuk u ≤≤ ( ) min max uuk u∆ ≤∆≤∆ min k max y yy≤≤ Details of MPC are discussed in [22-24]. 3. System Configuration 3.1. System Dynamics In this section, a simplified frequency response mode l for a single area power system with an aggregated generator unit is described [2]. The overall generator-load dynamic relationship be- tween the incremental mismatch power mL PP∆ −∆ and the frequency devia t ion f∆ can be expressed as: 11 .222 mL D sfPP f HHH ∆=⋅∆− ⋅∆− ⋅∆ (2) 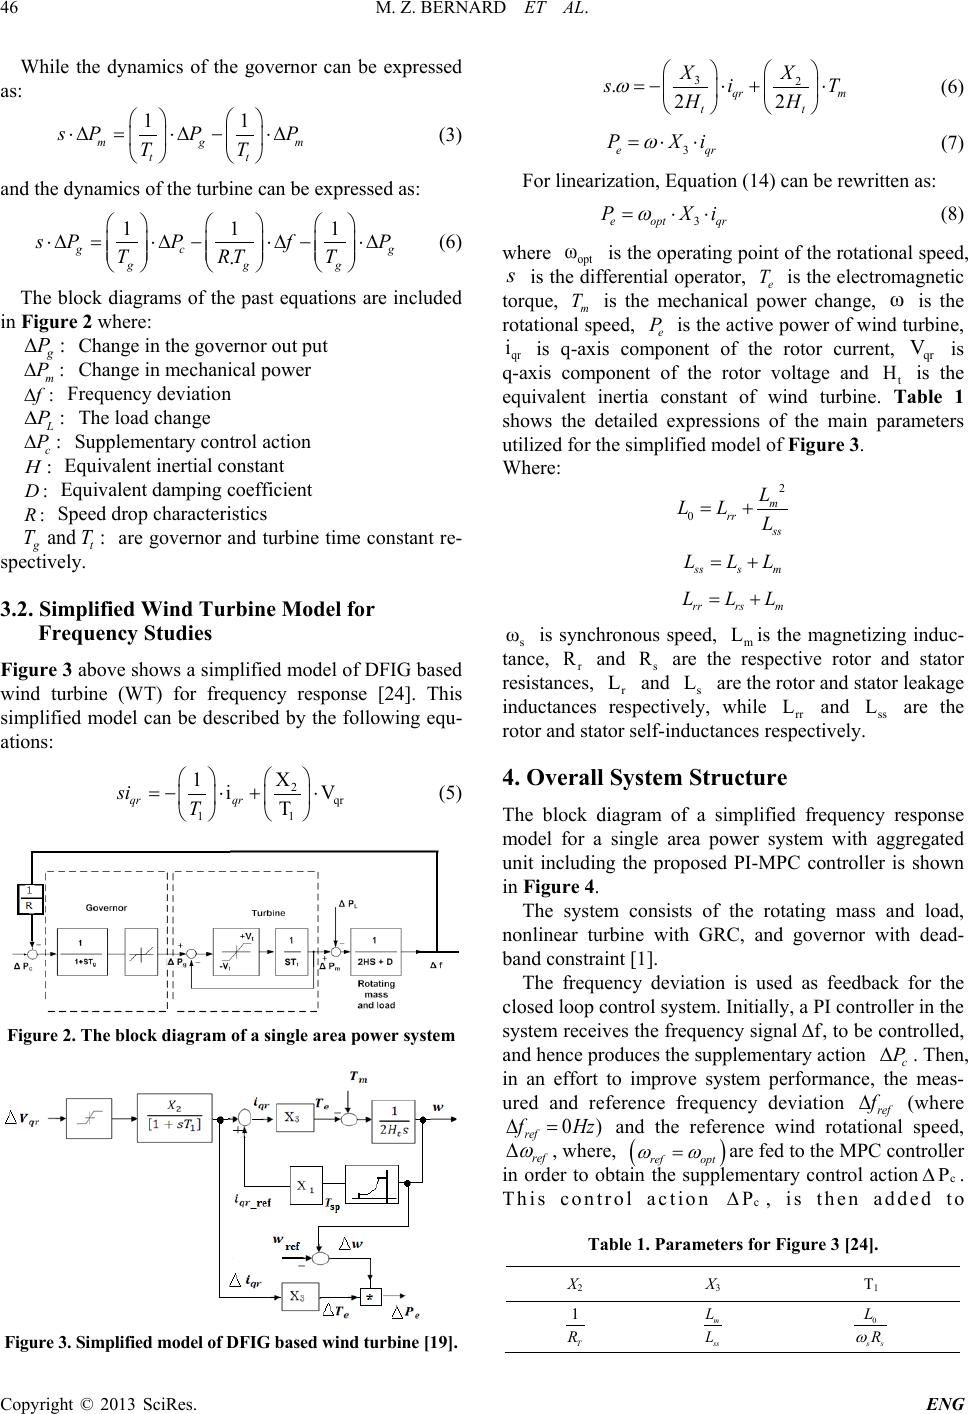 M. Z. BERNARD ET AL. Copyright © 2013 SciRes. ENG 46 While the dynamics of the governor can be expressed as: 11 m gm tt sPP P TT ⋅∆=⋅∆−⋅∆ (3) and the dynamics of the turbine can be expressed as: 1 11 . gc g g gg sPPf P TRT T ⋅∆=⋅∆−⋅∆ −⋅∆ (6) The block diagrams of the past equations are included in Figure 2 where: : g P∆ Change in the governor out put : m P∆ Change in mechanical power :f∆ Frequency deviation : L P∆ The load change : c P∆ Supplementary control action :H Equivalent inertial constant :D Equiva l e nt damping coefficient :R Speed drop characteristics and : gt TT are governor and turbine time constant re- spectively. 3.2. Simplified Wind Turbine Model for Frequency Studies Figu re 3 above shows a simplified model of DFIG based wind turbine (WT) for frequency response [24]. This simplified model can be described by the following equ- ations: 2qr 11 X 1iV T qr qr si T =−⋅+⋅ (5) Figure 2. The block diagram of a single area power system Figure 3. Simplified model of DFIG based wind turbine [19]. 32 .22 qr m tt XX s iT HH ω =− ⋅+⋅ (6) 3e qr P Xi ω =⋅⋅ (7) For linearization, Equation (14) can be rewritten as: 3e optqr P Xi ω = ⋅⋅ (8) where opt ω is the operating point of the rotational speed, s is the differential operator, e T is the electromagnetic torque, m T is the mechanical power change, ω is the rotational speed, e P is the active power of wind turbine, qr i is q-axis component of the rotor current, qr V is q-axis component of the rotor voltage and t H is the equivalent inertia constant of wind turbine. Table 1 shows the detailed expressions of the main parameters utilized for the simplified model of Figure 3. Where: 2 0m rr ss L LL L = + sss m L LL= + rrrs m LLL= + s ω is synchronous speed, m Lis the magnetizing induc- tance, r R and s R are the respective rotor and stator resistances, r L and s L are the rotor and stator leakage inductances respectively, while rr L and ss L are the rotor and stator self-inductances respectively. 4. Overall System Structure The block diagram of a simplified frequency response model for a single area power system with aggregated unit including the proposed PI-MPC controller is shown in Figure 4. The system consists of the rotating mass and load, nonlinear turbine with GRC, and governor with dead- band constraint [1]. The frequency deviation is used as feedback for the closed loop control system. Initially, a PI controller in the system receives the frequency signal ∆f , to be controlled, and hence produces the supplementary action Δ c P . Then, in an effort to improve system performance, the meas- ured and reference frequency deviation ref f∆ (where 0) ref f Hz∆= and the reference wind rotational speed, ref ω ∆ , where, ( ) ref opt ωω = are fed to the MPC controller in order to obtain the supplementary control action c P∆ . This control action c P∆ , is then added to Table 1. Parameters for Fi gure 3 [24]. X2 X3 T1 1 T R m ss L L 0 ss L R ω 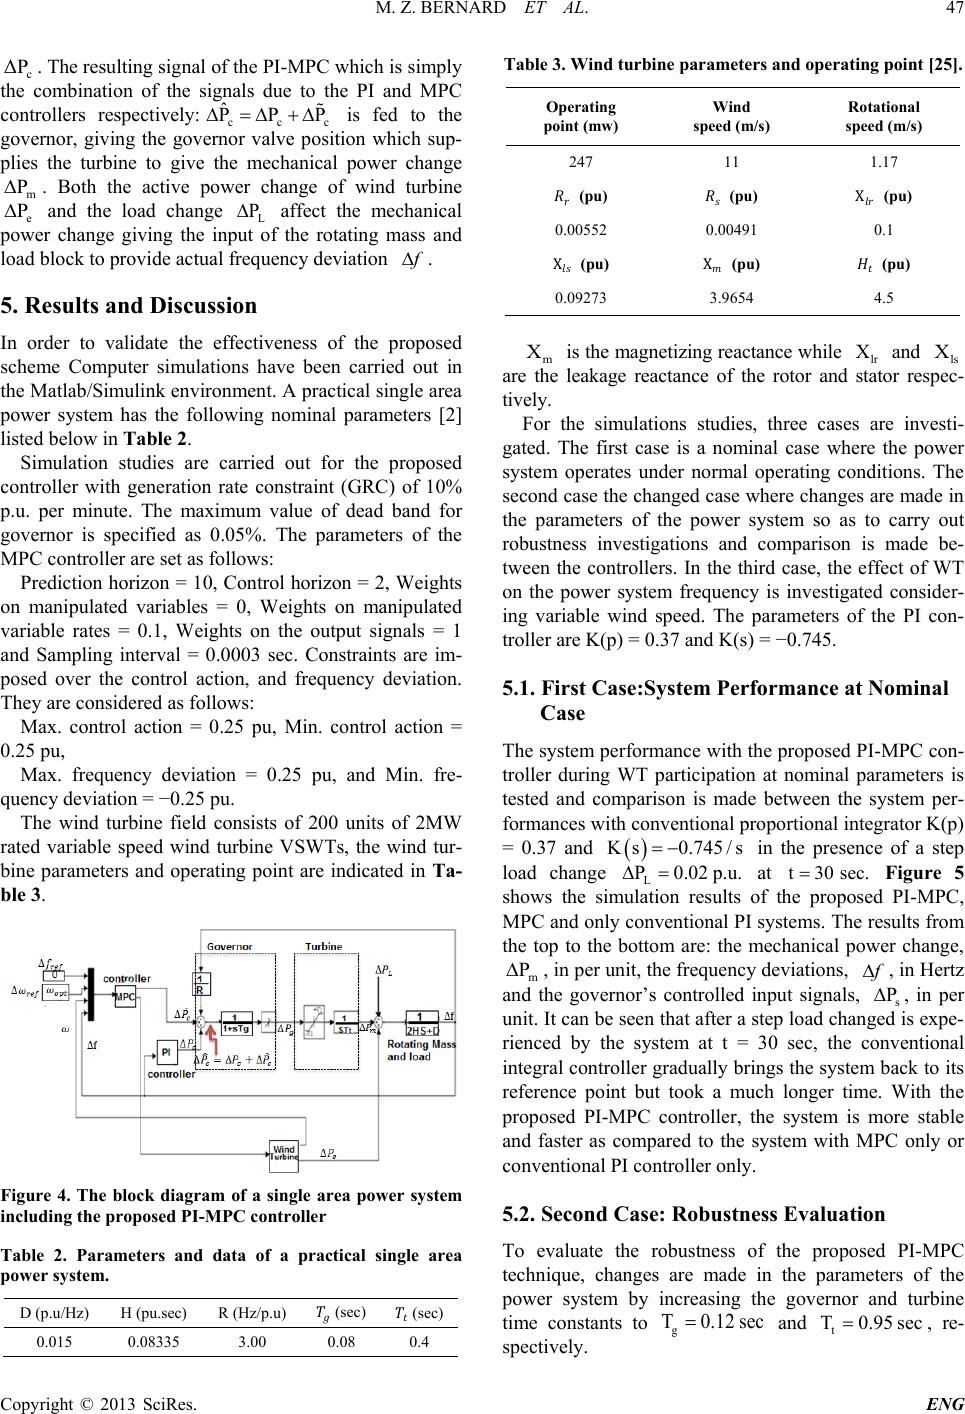 M. Z. BERNARD ET AL. Copyright © 2013 SciRes. ENG 47 c ΔP . The resulting signal of the PI-MPC which is simply the combination of the signals due to the PI and MPC controllers respectively: c cc ˆ PPP∆=∆ +∆ is fed to the governor, giving the governor valve position which sup- plies the turbine to give the mechanical power change m P∆ . Both the active power change of wind turbine e P∆ and the load change L P∆ affect the mechanical power change giving the input of the rotating mass and load bloc k to provide ac tual frequency deviation f∆ . 5. Results and Discussion In order to validate the effectiveness of the proposed scheme Computer simulations have been carried out in the Matlab/Simulink environment. A practical single area power system has the following nominal parameters [2] listed below in Table 2. Simulation studies are carried out for the proposed controller with generation rate constraint (GRC) of 10% p.u. per minute. The maximum value of dead band for governor is specified as 0.05%. The parameters of the MPC controller are set as follows: Prediction horizon = 10, Control hor izon = 2, Weights on manipulated variables = 0, Weights on manipulated variable rates = 0.1, Weights on the output signals = 1 and Sampling interval = 0.0003 sec. Constraints are im- posed over the control action, and frequency deviation. They are considered as follows: Max. control action = 0.25 pu, Min. control action = 0.25 pu, Max. frequency deviation = 0.25 pu, and Min. fre- quency de vi a tion = −0.25 pu. The wind turbine field consists of 200 units of 2MW rated variable speed wind turbine VSWTs, the wind tur- bine parameters and operating point are indicated in Ta- ble 3. Figure 4. The block diagram of a single area power system including the proposed P I -MPC controller Table 2. Parameters and data of a practical single area power system. D (p.u/Hz) H (pu.sec) R (Hz/p.u) (sec) (sec) 0.015 0.08335 3.00 0.08 0.4 Table 3. Wind turbine parameter s an d op erating point [25]. Operating point (mw) Wind speed (m/s ) Rotational speed (m/s ) 247 11 1.17 (pu) (pu) X (pu) 0.00552 0.00491 0.1 X (pu) X (pu) (pu) 0.09273 3.9654 4.5 m X is the magnetizing reactance wh ile lr X and ls X are the leakage reactance of the rotor and stator respec- tively. For the simulations studies, three cases are investi- gated. The first case is a nominal case where the power system operates under normal operating conditions. The second case the changed case where changes are made in the parameters of the power system so as to carry out robustness investigations and comparison is made be- tween the controllers. In the third case, the effect of WT on the power system frequency is investigated consider- ing variable wind speed. The parameters of the PI con- troller are K( p) = 0.37 and K(s) = −0.745. 5.1. First Case:System Performance at Nominal Case The system performance with the proposed PI-MPC con- troller during WT participation at nominal parameters is tested and comparison is made between the system per- formances with conventional proportional integrator K(p) = 0.37 and ( ) Ks0.745 / s= − in the presence of a step load change L P0.02 p.u.∆= at t30 sec.= Figure 5 shows the simulation results of the proposed PI-MPC, MPC and only conven tional PI sys tems. The resu lts from the top to the bottom are: the mechanical power change, m P∆ , in per unit, the frequency deviations, f∆ , in Hertz and the governor’s controlled input signals, s P∆ , in per unit. It can be seen that after a step load changed is expe- rienced by the system at t = 30 sec, the conventional integral controller gradually brings the system back to its reference point but took a much longer time. With the proposed PI-MPC controller, the system is more stable and faster as compared to the system with MPC only or conventional PI controller only. 5.2. Second Case: Robustness Evaluat ion To evaluate the robustness of the proposed PI-MPC technique, changes are made in the parameters of the power system by increasing the governor and turbine time constants to g T0.12sec= and t T0.95 sec=, re- spectively. 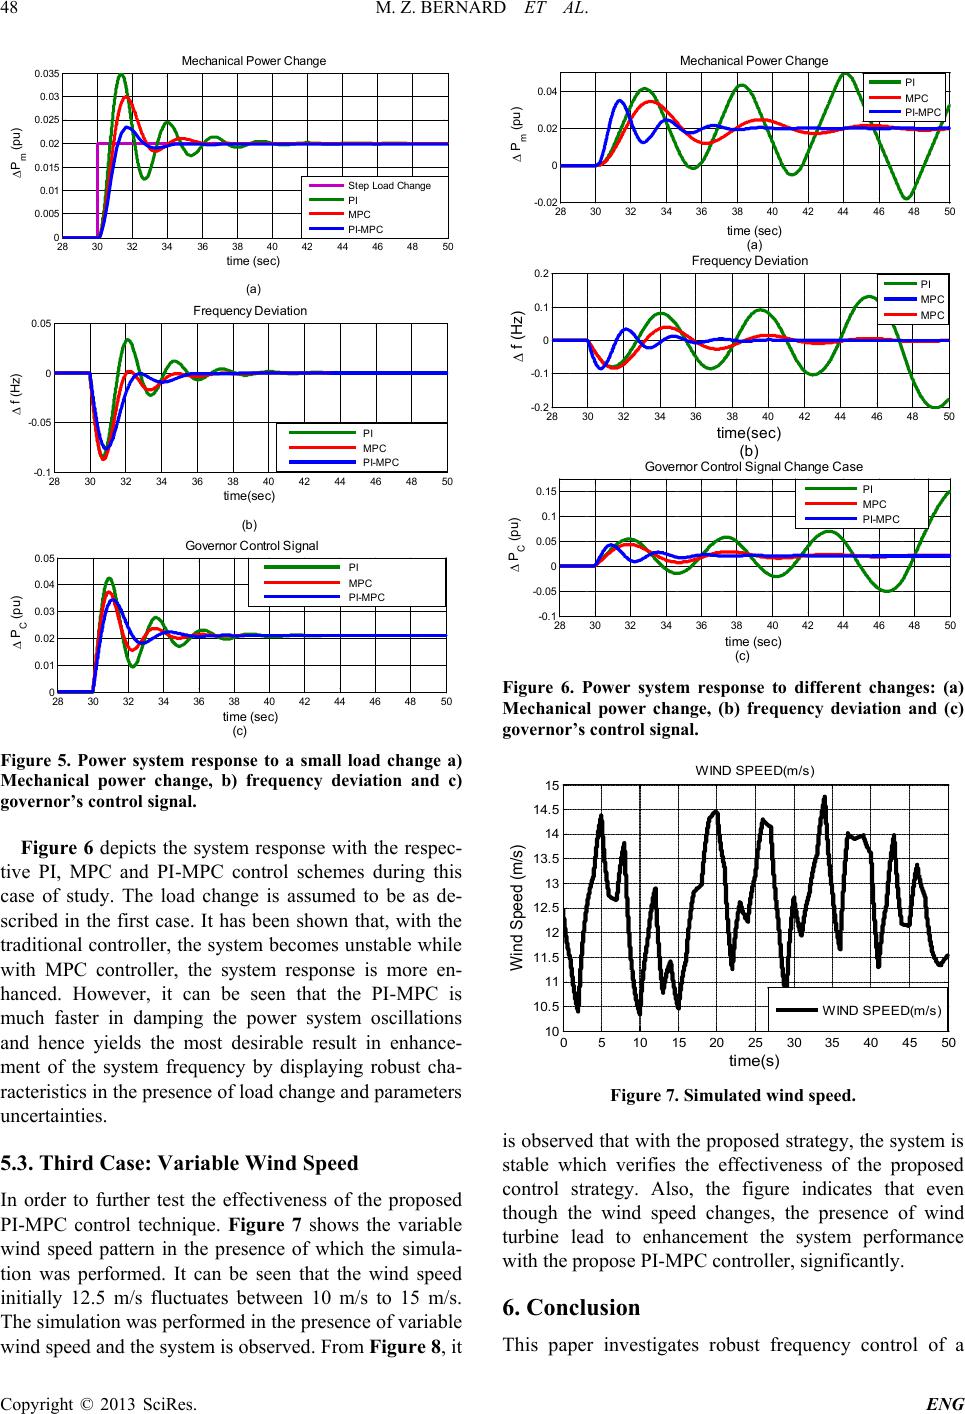 M. Z. BERNARD ET AL. Copyright © 2013 SciRes. ENG 48 Figure 5. Power system response to a small load change a) Mechanical power change, b) frequency deviation and c) governor’s control signal. Figure 6 depicts the system response with the respec- tive PI, MPC and PI-MPC control schemes during this case of study. The load change is assumed to be as de- scribed in the first case. It has been shown that, with the traditional controller , the system becomes unstab le while with MPC controller, the system response is more en- hanced. However, it can be seen that the PI-MPC is much faster in damping the power system oscillations and hence yields the most desirable result in enhance- ment of the system frequency by displaying robust cha- racteristics in the presence of load change and p arameters uncertainties. 5.3. Third Case: Variable Wind Speed In order to further test the effectiveness of the proposed PI-MPC control technique. Figure 7 shows the variable wind speed pattern in the presence of which the simula- tion was performed. It can be seen that the wind speed initially 12.5 m/s fluctuates between 10 m/s to 15 m/s. The simulation was performed in the presence of variable wind speed and the system is observed. From Figure 8, it Figure 6. Power system response to different changes: (a) Mechanical power change, (b) frequency deviation and (c) governor’s control signal. Figure 7. Simulated wind speed. is observed that with the proposed strategy, the system is stable which verifies the effectiveness of the proposed control strategy. Also, the figure indicates that even though the wind speed changes, the presence of wind turbine lead to enhancement the system performance with the propose P I -MPC controller, significantly. 6. Conclusion This paper investigates robust frequency control of a 28 30 32 343638 40 424446 4850 0 0.005 0.01 0.015 0.02 0.025 0.03 0.035 time (sec) (a) ∆P m (p u) Mechanical Pow er Change Step Load Change PI MPC PI-MPC 28 30 32 34 36 38 40 42 44 46 48 50 -0.1 -0.05 0 0.05 ti me(sec) (b) ∆ f (Hz) Frequency Deviat ion PI MPC PI-MPC 28 30 32 34 36 38 40 42 44 4648 50 0 0.01 0.02 0.03 0.04 0.05 time (sec) (c) ∆ P C (p u) Govern or Cont r ol Sign al PI MPC PI-MPC 28 3032 3436 3840 42 4446 48 50 -0.02 0 0. 02 0. 04 Mechanical Pow er Ch ange time (sec) (a) ∆ P m (p u) PI MPC PI-MPC 28 3032 34 363840 42 444648 50 -0.2 -0.1 0 0. 1 0.2 Frequency Dev iat ion time(sec) (b) ∆ f (Hz) PI MPC MPC 28 3032 34 3638 40 42 44 46 4850 -0.1 -0.05 0 0. 05 0. 1 0. 15 Govern or Cont r ol Sign al Change Case time (sec) (c) ∆ P C (p u) PI MPC PI-MPC 05101520 25 3035 40 45 50 10 10.5 11 11.5 12 12.5 13 13.5 14 14.5 15 time (s) Wind Speed ( m / s) WIND SPEED(m/s) WIND SPEED(m/s) 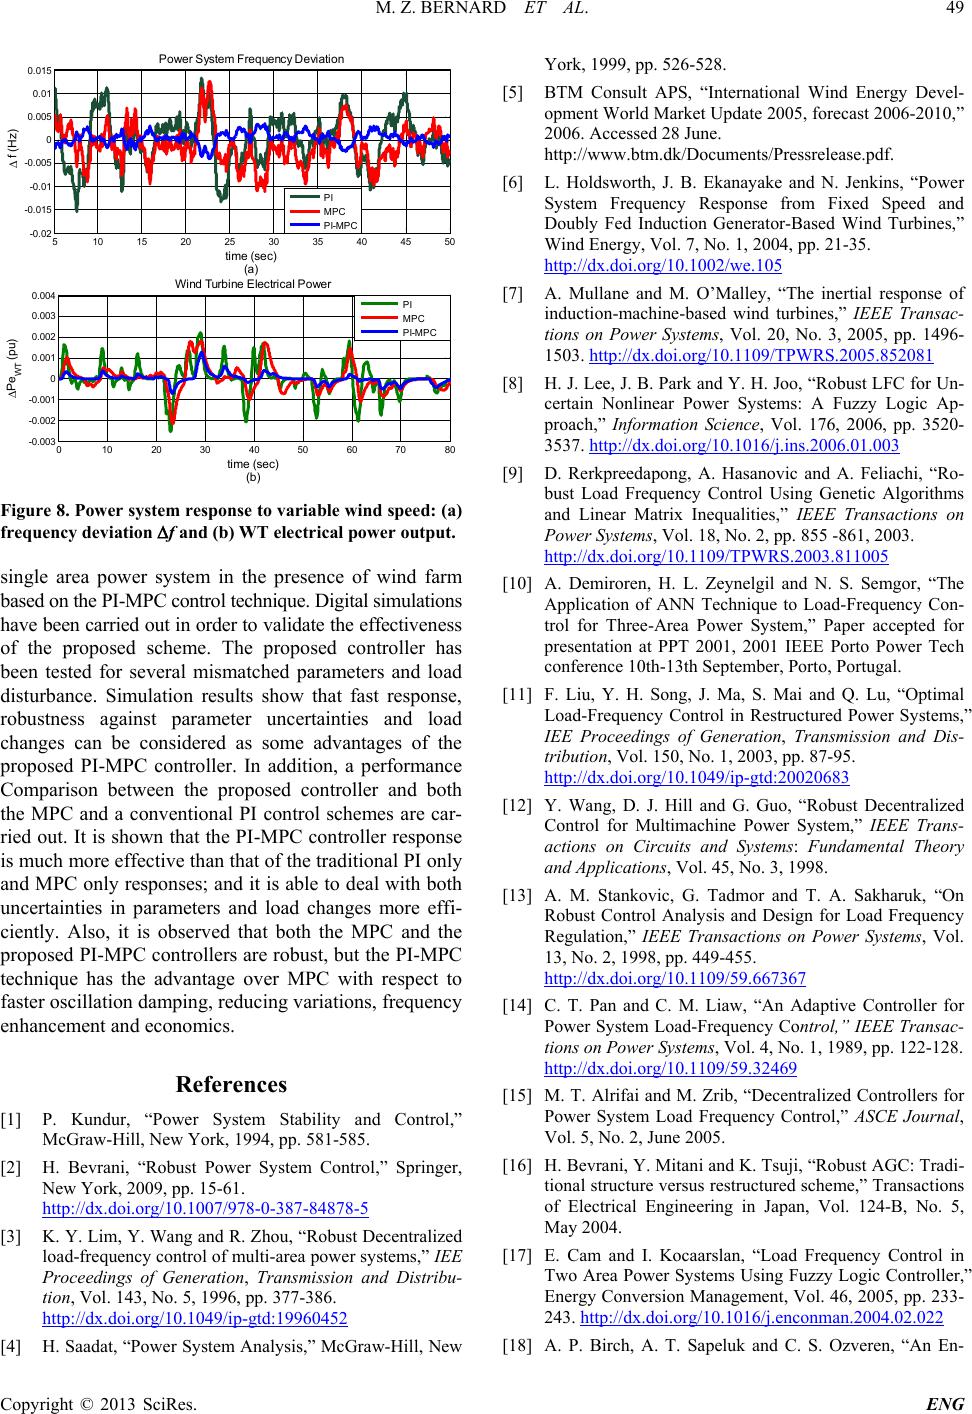 M. Z. BERNARD ET AL. Copyright © 2013 SciRes. ENG 49 Figure 8. Power system response to variable wind speed: (a) frequency deviation ∆f and (b) WT electrical power output. single area power system in the presence of wind farm based on the P I-M PC control technique. Digital simulations have been carried out in order to validate the effectiveness of the proposed scheme. The proposed controller has been tested for several mismatched parameters and load disturbance. Simulation results show that fast response, robustness against parameter uncertainties and load changes can be considered as some advantages of the proposed PI-MPC controller. In addition, a performance Comparison between the proposed controller and both the MPC and a conventional PI control schemes are car- ried out. It is shown that the PI-MPC controller response is much more effective than that of the traditional PI only and MPC only respon ses; and it is able to deal with both uncertainties in parameters and load changes more effi- ciently. Also, it is observed that both the MPC and the proposed PI-MPC controllers are ro bust, but the PI-MPC technique has the advantage over MPC with respect to faster oscillation damping, reducing variations, frequency enhancement and economics. References [1] P. Kundur, “Power System Stability and Control,” McGraw-Hill, New York, 1994, pp. 581-585. [2] H. Bevrani, “Robust Power System Control,” Springer, New York, 2009, pp. 15-61. http://dx.doi.org/10.1007/978-0-387-84878-5 [3] K. Y. Lim, Y. Wang and R. Zhou, “Robust Decentralized load-frequency control of multi-area powe r systems,” IEE Proceedings of Generation, Transmission and Distribu- tion, Vol. 143, No. 5, 1996, pp. 377-386. http://dx.doi.org/10.1049/ip-gtd:19960452 [4] H. Saadat, “Powe r System Analysis,” McGraw-Hill, New York, 1999, pp. 526-528. [5] BTM Consult APS, “International Wind Energy Devel- opment World Market Update 2005, forecast 2006-2010,” 2006. Accessed 28 June. http://www.btm.dk/Documents/Pressrelease.pdf. [6] L. Holdsworth, J. B. Ekanayake and N. Jenkins, “Power System Frequency Response from Fixed Speed and Doubly Fed Induction Generator-Based Wind Turbines,” Wind Energy, Vol. 7, No. 1, 2004, pp. 21-35. http://dx.doi.org/10.1002/we.105 [7] A. Mullane and M. O’Malley, “The inertial response of induction-machine -based wind turbines,” IEEE Transac- tions on Power Systems, Vol. 20, No. 3, 2005, pp. 1496- 1503. http://dx.doi.org/10.1109/TPWRS.2005.852081 [8] H. J. Lee, J. B. Park and Y. H. Joo, “Robust LFC for Un- certain Nonlinear Power Systems: A Fuzzy Logic Ap- proach,” Information Science, Vol. 176, 2006, pp. 3520- 3537. http://dx.doi.org/10.1016/j.ins.2006.01.003 [9] D. Rerkpreedapong, A. Hasanovic and A. Feliachi, “Ro- bust Load Frequency Control Using Genetic Algorithms and Linear Matrix Inequalities,” IEEE Transactions on Power Systems, Vol. 18, No. 2, pp. 855 -861, 2003. http://dx.doi.org/10.1109/TPWRS.2003.811005 [10] A. Demiroren, H. L. Zeyne l gi l and N. S. Semgor, “The Application of ANN Technique to Load-Frequency Con- trol for Three-Area Power System,” Paper accepted for presentation at PPT 2001, 2001 IEEE Porto Power Tech conference 10th-13th September, Porto, Portugal. [11] F. Liu, Y. H. Song, J. Ma, S. Mai and Q. Lu, “Optimal Load-Frequency Control in Restructured Power Systems,” IEE Proceedings of Generati on, Transmission and Dis- tribution, Vol. 150, No. 1, 2003, pp. 87-95. http://dx.doi.org/10.1049/ip-gtd:20020683 [12] Y. Wang, D. J. Hill and G. Guo, “Robust Decentralized Control for Multimachine Power System,” IEEE Trans- actions on Circuits and Sy stems: Fundamental Theory and Applications, Vol. 45, No. 3, 1998. [13] A. M. Stankovic, G. Tadmor and T. A. Sakharuk, “On Robust Control Analysis and Design for Load Frequency Regulation,” IEEE Transactions on Power Systems, Vol. 13, No. 2, 1998, pp. 449-455. http://dx.doi.org/10.1109/59.667367 [14] C. T. Pan and C. M. Liaw, “An Adaptive Controller for Power System Load-Frequency Control,” IEEE Transac- tions on Power Systems, Vol. 4, No. 1, 1989, pp. 122-128. http://dx.doi.org/10.1109/59.32469 [15] M. T. Alrifai and M. Zr ib, “Decentralized Controllers for Power System Load Frequency Control,” ASCE Journal, Vol. 5, No. 2, June 2005. [16] H. Bevrani, Y. Mitani and K. Tsuji, “Robust AGC: Tradi- tional structure versus restructured scheme,” Transactions of Electrical Engineering in Japan, Vol. 124-B, No. 5, May 2004. [17] E. Cam and I. Kocaarslan, “Load Frequency Control in Two Area Power Systems Using Fuzzy Logic Controller,” Energy Conversion Management, Vol . 46, 2005, pp. 233- 243. http://dx.doi.org/10.1016/j.enconman.2004.02.022 [18] A. P. Birch, A. T. Sapeluk and C. S. Ozveren, “An En- 510152025303540 45 50 -0.02 -0.015 -0.01 -0.005 0 0.005 0.01 0.015 Power System Frequency Dev iat ion time (sec) (a) ∆ f (Hz) PI MPC PI-MPC 010 20 30 40 50 60 70 80 -0.003 -0.002 -0.001 0 0.001 0.002 0.003 0.004 time (sec) (b) ∆Pe WT (p u) Win d Tur bine El ect r ical Pow er PI MPC PI-MPC 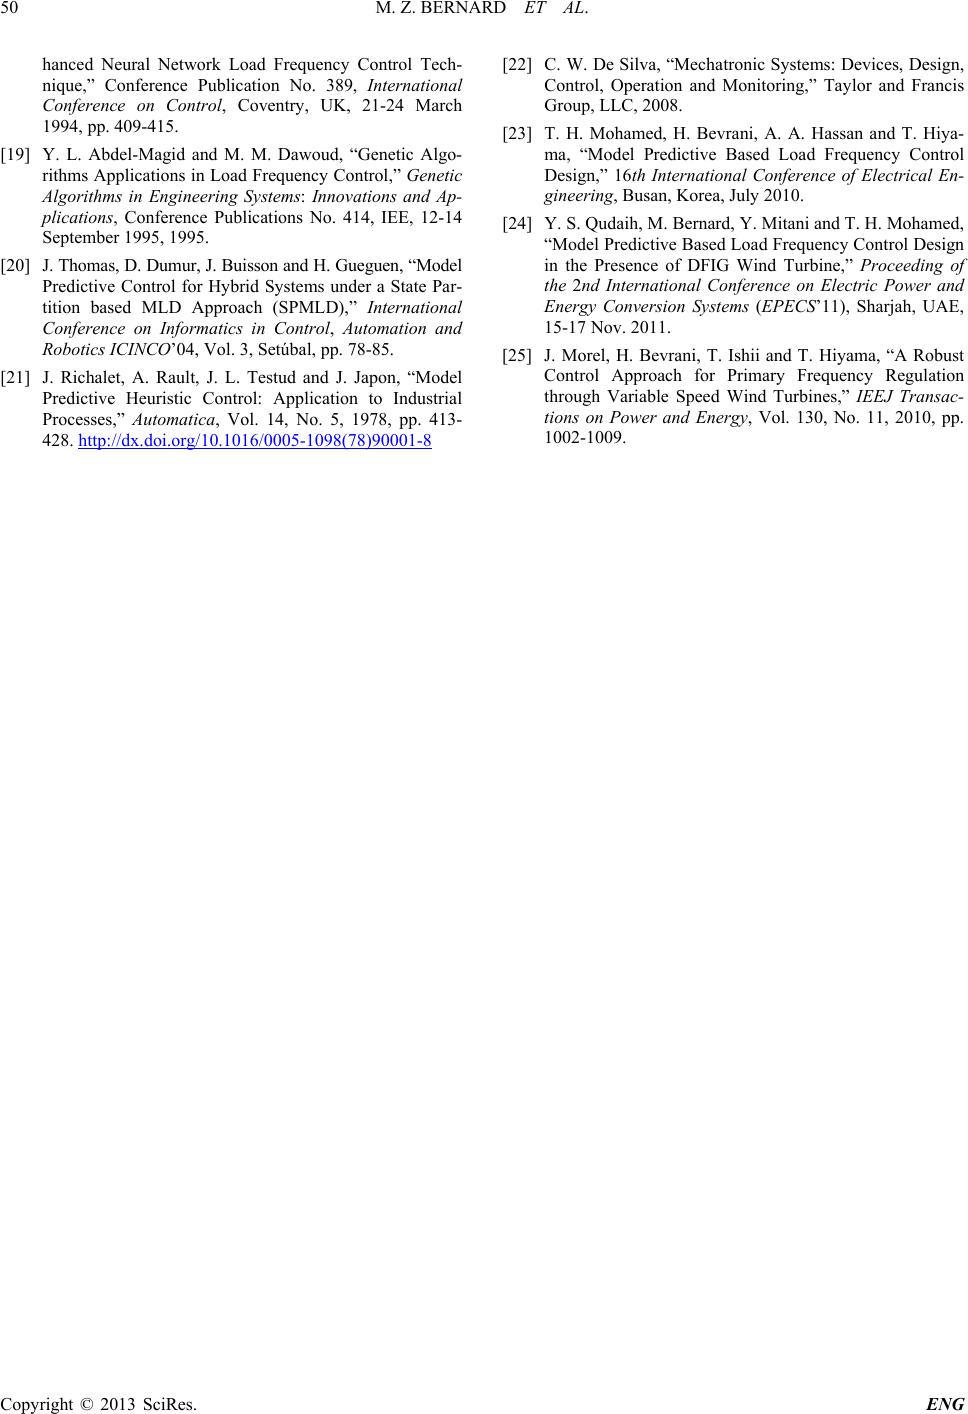 M. Z. BERNARD ET AL. Copyright © 2013 SciRes. ENG 50 hanced Neural Network Load Frequency Control Tech- nique,” Conference Publication No. 389, International Conference on Control, Coventry, UK, 21-24 March 1994, pp. 409-415. [19] Y. L. Abdel-Magid and M. M. Dawoud, “Genetic Algo- rithms Applications in Load Frequency Control,” Genetic Algorithms in Engineering Systems: Innovations and Ap- plications, Conference Publications No. 414, IEE, 12-14 September 1995, 1995. [20] J. Thomas, D. Dumur, J. Buisson and H. Gueguen, “Model Predictive Control for Hybrid Systems under a State Par- tition based MLD Approach (SPMLD),” International Conference on Informatics in Control, Automation and Robotics ICINCO’04, Vol. 3, Setúbal, pp. 78-85. [21] J. Richalet, A. Rault, J. L. Testud and J. Japon, “Model Predictive Heuristic Control: Application to Industrial Processes,” Automatica, Vol. 14, No. 5, 1978, pp. 413- 428. http://dx.doi.org/10.1016/0005-1098(78)90001-8 [22] C. W. De Silva, “Mechatronic Systems: Devices, Design, Control, Operation and Monitoring,” Taylor and Francis Group, LLC, 2008. [23] T. H. Mohamed, H. Bevrani, A. A. Hassan and T. Hiya- ma, “Model Predictive Based Load Frequency Control Design,” 16th International Conference of Electrical En- gineering, Busan, Korea, July 2010. [24] Y. S. Qudaih, M. Bernard, Y. Mitani and T. H. Mohamed, “Model Predictive Based Load Frequency Control Design in the Presence of DFIG Wind Turbine,” Proceeding of the 2nd International Conference on Electric Power and Energy Conversion Systems (EPECS’11), Sharjah, UAE, 15-17 Nov. 2011. [25] J. Morel, H. Bevrani, T. Ishii and T. Hiyama, “A Robust Control Approach for Primary Frequency Regulation through Variable Speed Wind Turbines,” IEEJ Transac- tions on Power and Energy, Vol. 130, No. 11, 2010, pp. 1002-1009. |